Strengthening Autonomous Truck Safety Through First Responder Collaboration

Strengthening Autonomous Truck Safety Through First Responder Collaboration

Torc truck reflection in side mirror

Bringing Real-World Expertise to Autonomous Vehicle Development

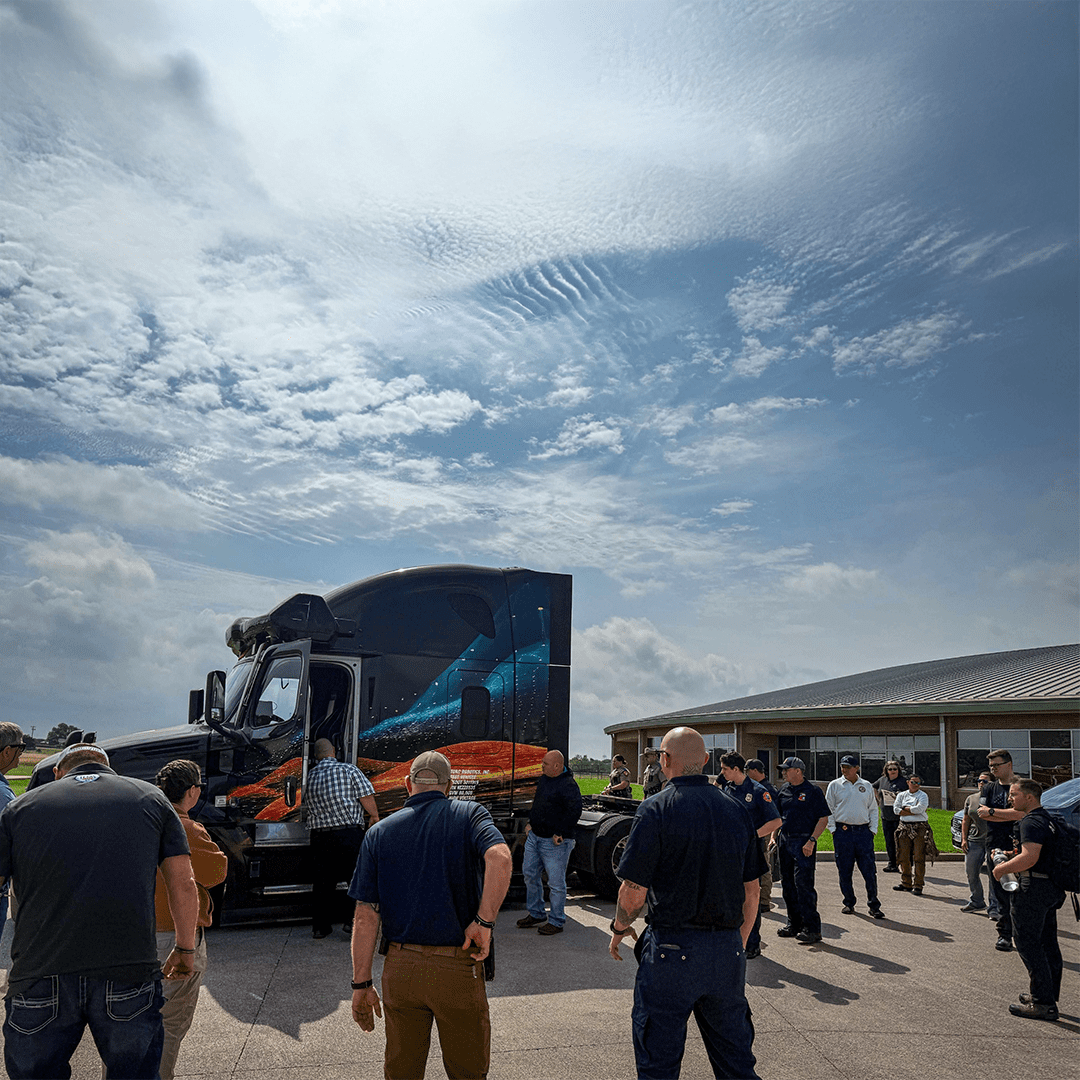
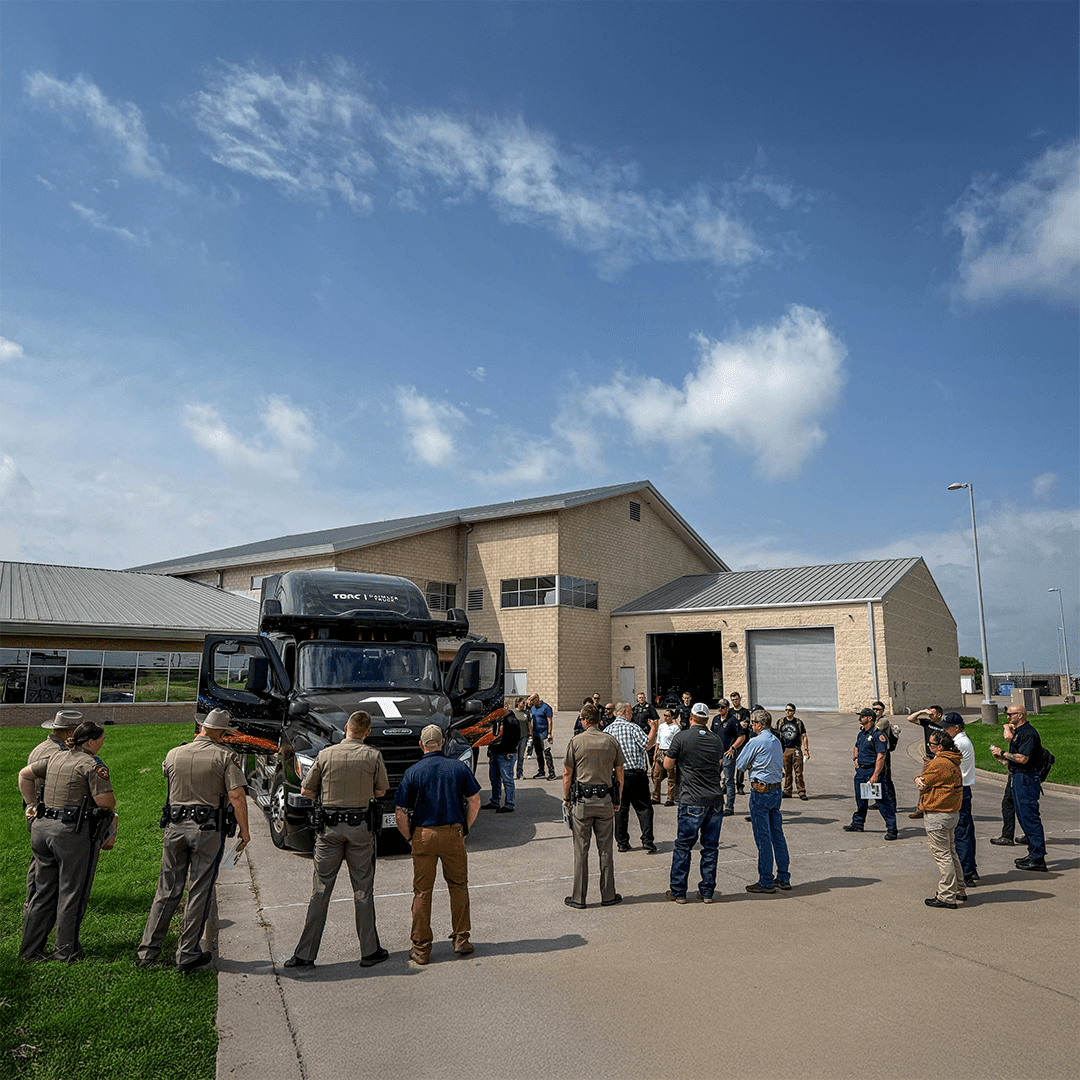
On July 16, 2026, law enforcement officers, firefighters, and EMS personnel from agencies across the southwest Virginia region joined Torc engineers and safety experts for a series of targeted testing exercises at the Virginia Tech Transportation Institute (VTTI) Smart Road closed-course test track to further evaluate how our self-driving truck detects, interprets, and responds to emergency vehicles and personnel in real-world scenarios.

The goal was simple but critical: to better understand how autonomous vehicles can safely and effectively interact with emergency responders in dynamic traffic situations as well as roadside environments.

Using our most recent generation of Torc self-driving trucks (SDTs) on the VTTI Smart Road, the team conducted emergency vehicle (EMV) data collection across a variety of realistic scenarios. These exercises allowed Torc to expand its training dataset, gather valuable operational insights, and further improve the system’s ability to recognize and respond appropriately to emergency situations.

For autonomous vehicles operating on public roads, emergency interactions represent some of the most complex and unpredictable conditions they may encounter. Ensuring that self-driving trucks can accurately detect emergency vehicles, interpret responder actions, and make safe driving decisions is an essential part of building a dependable autonomous system.

Learning From Those Who Know the Road Best

First responders bring a unique perspective that informs Torc engineers as they build our technology. Throughout the testing exercises, participating officers, firefighters, and EMS personnel shared insights based on years of frontline experience. From traffic stops and roadside incidents to emergency response situations, these professionals understand how complex these situations can become. Their feedback helps Torc refine how Torc’s autonomous truck perceives and reacts to these complex scenes, improving the predictability of the autonomous truck, and ultimately increasing the safety for responders, other motorists, and the communities where autonomous vehicles will operate. “First responders need clear answers in emergency situations: Will the autonomous vehicle stay put or move? Can they safely work around it? Is anyone inside? Our First Responder Interaction Plan was designed to address those critical questions, “says Richard Russell, Senior Program Manager, First Responder Policy.

Expanding Data, Improving Performance

The event also delivered significant technical value.

High-quality emergency vehicle and responder interaction data is critical for improving perception systems. Every scenario performed at the test track contributes to a broader and more diverse dataset that can be used to enhance the truck’s ability to recognize emergency vehicles under varying conditions and respond appropriately.

“Collaboration with first responders is essential to developing safe, reliable autonomous vehicle technology,” says Erik Kinservik, Director of Engineering. “Working directly with law enforcement, fire, and EMS helps us understand real-world operational needs and ensures our vehicles respond appropriately in emergency situations, improving safety, supporting effective emergency response, and building public trust.”

“Using our latest generation vehicle, we expanded our high-quality data set, covering a wide breadth of scenarios across the multiple onsite police, fire, and rescue vehicles,” says Zach Joswick, Senior Software Engineer. “By capturing this widely varied data in both static and dynamic situations, our AV 3.0 software can learn the diverse range of shapes and sizes of EMVs and respond accordingly. Our simulation environment can take the captured data, and generate thousands of permutations to even further enhance the AV 3.0 model’s capability to respond to complex emergency situations.”

By expanding this data foundation, Torc continues to strengthen the reliability and robustness of its autonomous driving system, ensuring it is prepared to operate safely across a wide range of real-world situations.

Three Torc trucks, taken from above by drone
Photo of an autonomous truck visualization on screen

Building Partnerships That Matter

Beyond the technical outcomes, collaborations like this reinforce the importance of strong relationships between autonomous vehicle developers and the public safety community.

Developing autonomous technology is not something that happens in isolation. It requires ongoing collaboration with the people who will interact directly with these systems on the road. By working side by side with first responders, Torc receives valuable operational insight from industry experts while providing transparency into how autonomous vehicles are being developed and tested.

“Building autonomous technology isn’t just about advancing the vehicle. It’s about building strong partnerships with the people who will interact with it every day,” says Russell. “Working alongside first responders helps us create safer systems while fostering the trust that’s essential for successful deployment.”

These partnerships help ensure that safety remains at the center of innovation while also building trust among stakeholders and the broader public.

A Shared Commitment to Safer Roads

The success of Torc’s alliance with First Responders highlights what can be accomplished when diverse groups come together around a common mission. Engineers, operators, law enforcement officers, firefighters, and EMS personnel regularly collaborate to advance a shared goal: creating safer roadways through thoughtful innovation and rigorous testing.

“Ongoing engagement is essential because we know we won’t anticipate every question. That’s why maintaining an open dialogue with first responders is such an important part of what we do,” says Russell.

As Torc continues to develop autonomous trucking technology, ongoing collaboration with first responders will remain a critical part of the journey. Their expertise, partnership, and dedication help us build systems that are not only technologically advanced, but also safe, practical, and responsive to the realities of the road.

At Torc, safety is the foundation of everything we do. Building a safe and reliable autonomous trucking solution requires more than advanced technology. It requires close collaboration with the people who work every day to keep our roads safe, and together, we are helping shape the future of transportation, one built on safety, operational integrity, and strong collaboration.

The Future of Physical AI in Transportation and Freight

The Future of Physical AI in Transportation and Freight

Torc truck reflection in side mirror

This series began by drawing the line between digital AI and physical AI, then showed how that line resolves in freight: physical AI is not a new arrival, it is the destination the trucking industry has been building toward for decades. This piece closes that arc — tracing how the shift plays out across the full freight ecosystem, and why it starts where the series said it would: on the highway, not the warehouse floor.

Because freight has never been a digital-only problem. It has always been a physical one.

From Information to Interaction

The physical world is complicated. It is not just words and patterns. It is movement, geometry, timing, weather, load conditions, safety, and constant variability. A machine operating in the physical world must do more than predict what will come next. It must understand what is in front of it, what is changing around it, and what action is appropriate in that moment. That is why physical AI is more difficult to build than digital AI — and why it may ultimately be more valuable. For freight, this distinction is critical. The industry has spent decades improving visibility, route efficiency, telematics, and automation. Those advances have been meaningful. But they were still largely built around rules, workflows, and predefined responses. Physical AI changes the logic. Instead of simply following instructions, systems begin to learn from the environment itself.

Why Freight Is a Natural Fit

Freight transportation is one of the clearest examples of a sector where physical AI can matter at scale. Why? Because freight is already a world of structured motion. There are routes, schedules, dock appointments, trailer movements, loading requirements, constrained spaces, and operational standards. But it is also a world of exceptions. Traffic changes. Weather shifts. Demand spikes. Labor fluctuates. Equipment breaks. Customers adjust. No two days are exactly alike. That combination makes freight a strong candidate for physical AI. The industry needs systems that can do more than execute fixed tasks. It needs systems that can interpret conditions, adapt to uncertainty, and support better decisions in real time. That is the promise of physical AI in transportation and logistics. Not replacement for the sake of replacement. Not novelty for the sake of novelty. But more intelligent operations in places where complexity has always been the challenge.

The Beachhead Is the Highway and The Rest of the Ecosystem Follows

A lot of people think about physical AI in freight and jump straight to autonomous trucks. That’s not wrong — it’s where TorcDrive, and the physical AI destination this series has been describing, is proving out first: on high-volume interstate corridors and predictable long-haul lanes. But autonomous trucks are the leading edge, not the whole story.

The future of AI in freight is broader than one vehicle or one use case. As the operational envelope expands beyond the highway, it includes:
• Warehouse robotics that can understand changing environments
• Yard systems that can coordinate movement more intelligently
• Predictive maintenance tools that can interpret physical signals before equipment fails
• Load optimization systems that adapt to operational constraints
• Safety systems that detect risk in real time
• Material handling systems that can perform more than one task
• Decision support tools that help people act faster and with more confidence

That is the real strategic shift. Physical AI is not just about making one machine smarter. It is about making the entire freight ecosystem more adaptive — starting from the proven beachhead outward.

Why It Will Scale in Stages

One of the most important things to understand about physical AI is that it will not scale all at once.

The freight industry has seen enough technology cycles to know that adoption follows a pattern. The first step is usually proving value in a controlled environment. The next step is expanding into adjacent use cases. Then the technology broadens into more variable and more complex settings.

Physical AI is following that same arc — and freight is a live example of it.

It starts where the environment is more structured and the operating domain is narrower — which, in freight, can mean high-volume interstate corridors and predictable long-haul lanes before it means anything else. That’s not a generic adoption pattern; it’s the specific sequence physical AI is already following in trucking today, and why autonomous highway operation is the furthest along of any freight application.

From that foundation, warehouses, yards, and other constrained settings become the next expansion, because they offer their own version of the same combination: clear boundaries, measurable outcomes, manageable risk.

Over time, as systems learn and improve in each of those domains, the scope keeps expanding — and the domains start to connect.

That is not a limitation. It is how real adoption happens. The future of physical AI will not be defined by one massive leap. It will be defined by a sequence of practical, valuable steps that gradually build trust and capability, starting from the highway and moving outward.

Three Torc trucks, taken from above by drone
Photo of an autonomous truck visualization on screen

The Importance of Design Domain

Read this twice: physical AI will always operate within a design domain.

That matters because freight is not a laboratory. Real operations involve cost, risk, uptime, safety, and service commitments. Any technology that operates in that setting has to be designed with limits in mind.

The right question is not whether physical AI can do everything. The right question is where it can do something useful, reliably, and safely.

That is why the future of physical AI in transportation and freight is shaped by domain-specific deployment. For Torc, that domain starts on the highway — TorcDrive is built and proven for long-haul interstate operation first, with the same design-domain discipline expanding to warehouse floors, yards, terminals, and customer sites over time.

This is also why the future of freight AI will not be about a single universal platform. It will be about a growing set of systems, each built for its own operational context, but all driven by the same underlying shift: learning in the physical world, proven in the domain where it’s most ready before it expands into the next.

What Freight Leaders Should Be Watching

For freight executives and operators, the question is not whether physical AI is coming. It is already here in early forms.

The more useful questions are:
• Where are our most repetitive physical workflows?
• Where do exceptions create the most cost and delay?
• Where do we lack visibility?
• Where would better real-time interpretation improve operations?
• Which environments are structured enough for early adoption?
• What data are we already collecting, and what are we missing?

Those questions matter because the future of physical AI will not be won by hype. It will be won by operational clarity.
The companies that benefit first will be the ones that understand their workflows deeply enough to identify where intelligence can create measurable improvement.

Once that data became accessible, AI systems could be trained quickly and at scale.

That’s why digital AI feels like it “appeared overnight.” It was trained “in the cloud” of ever-expanding data centers, allowing for rapid iteration.  

Simulation Will Be a Major Accelerator

A key factor behind the future of physical AI is simulation.

Because physical-world data is harder to collect than digital data, simulation becomes a powerful way to train systems before they ever operate in live environments. That matters enormously for freight, where testing in the real world can be expensive, disruptive, or risky.

Simulation gives organizations the ability to create realistic operational conditions without needing to reproduce every experience physically. It allows AI models to encounter rare scenarios, learn from edge cases, and improve faster than they could through real-world trial and error alone.

At Torc, this is exactly how TorcDrive trains: on real-world data and complex simulated scenarios simultaneously, so the system encounters rare and safety-critical situations at a scale no on-road testing program could match alone.

That means the future is not just about more sensors or more hardware. It is also about better ways to create, train, and refine intelligence before it is deployed.

The Human Role Will Still Matter

As powerful as physical AI may become, freight is still a human industry.

Drivers, planners, warehouse teams, dispatchers, maintenance staff, and operations leaders are not disappearing from the picture. If anything, their roles are becoming more important as the complexity of the system grows.

The most likely outcome is not that physical AI replaces people wholesale. It is that it changes what people spend their time doing.

That shift matters.

When systems take on more of the repetitive sensing, monitoring, or coordination work, humans can focus more on judgment, escalation, planning, and exception handling. That is where freight organizations can create a better balance between efficiency and resilience.

The future of physical AI is not just about machine capability. It is about how machines and people work together in environments where both matter.

AV3.O

The Bottom Line

The future of physical AI in transportation and freight is not a distant concept. It is the next layer of a broader shift already underway.

Digital AI taught us what machines can do with language, data, and information. Physical AI is showing us what they can do when they are connected to the real world.

For freight, that future is especially significant. This is an industry built on movement, coordination, and execution. It is an industry where better decisions can create real economic value. And it is an industry where the challenge has never been a lack of complexity — it has been how to manage that complexity better.

That is the destination this series has been describing since its first piece: not a detour from decades of automation investment, but where that investment was always leading. At Torc, TorcDrive and AV 3.0 are how that destination is arriving first — on the highway, in the segment of freight where the case for physical AI is proven today — with the rest of the ecosystem following the same arc behind it.

Physical AI will not eliminate freight’s complexity. But it will help freight organizations navigate it with greater intelligence, resilience, and precision.

And that may be the most important future of all.

From Automation to Physical AI: The Technical Destination Freight Has Been Building Toward

From Automation to Physical AI: The Technical Destination Freight Has Been Building Toward

For decades, the trucking industry has chased the same goal—move more freight, more reliably, at lower cost, safely—driving successive waves of investment in route optimization, telematics, electronic logging, and mechanized loading. But every wave shared a fundamental characteristic: it was designed to eliminate variability, not navigate it.

That distinction matters more than it might first appear—and understanding it explains why physical AI is not simply the next technology upgrade for freight. It is the destination the industry has been moving toward all along.

The Ceiling That Was Always There

Traditional automation works by reducing the number of decisions a system needs to make. Define the conditions, define the response, let the system execute. In structured environments—a fixed production line, a mechanized fulfillment center—this is extraordinarily effective.

Long-haul freight is different. U.S. trucks move over 72% of all domestic freight by weight across a $900 billion annual system running through inherently unpredictable conditions: shifting weather, variable traffic, tight delivery windows, regional infrastructure differences, and a workforce navigating real demographic and economic pressures that have no quick resolution.

Automation can make a skilled driver more efficient. It cannot provide the judgment skilled driving requires. That is the ceiling… and freight has been pressing against it for years.

What Changes with Physical AI

Physical AI is not a new concept arriving from outside the industry. It is the progression that emerges when AI design moves from pattern-matching and rule-following to environment-understanding and adaptive decision-making.

Where traditional automation asks “what condition matches this rule?”, physical AI asks “what is happening here, and what should I do about it?” Systems built on physical AI perceive their environment in real time, interpret changing conditions, and make decisions based on live inputs, not pre-programmed responses.

For trucking, that distinction is the difference between a system that helps manage a route and a system that can drive one.

This is why physical AI isn’t simply an upgrade to existing automation. It is the technical foundation for an entirely different class of operations, one where the system carries the judgment, adaptability, and situational awareness that freight has always demanded. And critically, it extends the operational envelope well beyond what any rule-based system can reach, giving freight networks the resilience and adaptability their scale has always required.

Where Deployment Starts and Where It Goes

Understanding how physical AI enters freight requires one key concept: the operational design domain, or ODD, the defined set of conditions in which a system operates reliably, and from which it expands. This is not a limitation. It is how serious technology deployment works, and it maps naturally onto how the freight industry itself is structured.

Early physical AI applications are concentrating on the conditions where they perform most reliably: high-volume interstate corridors, predictable long-haul lanes, and structured handoff environments—also, not coincidentally, the segments under the greatest cost and capacity pressure. Efficiency gains in fuel consumption, vehicle utilization, and operational uptime compound quickly across large fleets.

From that foundation, the envelope expands. As systems accumulate operational experience and capabilities mature, physical AI moves into more variable conditions, broader geographies, and more complex logistics environments. The trajectory follows the same arc as every major technology adoption the freight industry has seen: prove it in the highest-value, most predictable application first, then scale.

The Fuller Picture

Autonomous trucks on long-haul corridors are the most visible expression of physical AI in freight, but only one part of a broader shift across the entire logistics chain. Adaptive freight handling systems, warehouse robotics, intelligent fulfillment automation, and predictive maintenance platforms all reflect the same underlying change: systems that understand objectives, not just instructions, increasingly capable of operating in the environments that have always resisted full automation: dynamic, variable, and high-stakes.

What this means for freight over the next decade is a transition from fragmented, single-purpose tools to integrated, intelligent platforms. Fewer systems doing more. Greater resilience across supply chains. And a coherent answer to the operational complexity that has defined freight’s constraints for decades.

The Destination, Not a Detour

It would be easy to frame physical AI as another technology wave arriving to disrupt an industry that moves deliberately. That framing misses what’s actually happening.

The trucking industry has been building toward this for decades. Every automation investment—every route optimizer, every telematics platform, every mechanized dock—was a step toward more efficient, more reliable, more adaptive operations. Physical AI is not a detour from that path. It is where the path was always leading.

The industry that moves eleven billion tons of freight each year has always needed systems capable of operating intelligently in a dynamic, variable, real world. Those systems now exist. The question is no longer whether physical AI belongs in freight. It’s how quickly the industry builds on the foundation it has already spent decades laying.

Digital AI vs. Physical AI: What’s the Difference and Why It Matters

Digital AI vs. Physical AI: What’s the Difference and Why It Matters

Have you used AI to streamline your work or generate a list for you? Have you been fooled by an AI image? The technology we’ve been watching in movies for 20 years is now in our homes, cars, phones, and schools. Artificial intelligence is no longer theoretical. Most people—across industries and age groups—interact with tools like ChatGPT, Claude, or Gemini. Work apps like Zoom now offer AI summaries, and Microsoft and Adobe have generative AI tools built into their products. This widespread exposure has created a shared baseline: AI is useful, real, and improving quickly.

But there’s a critical distinction that’s still not widely understood—digital AI vs. physical AI.

Digital AI:

Intelligence On-screen

Digital AI operates in a purely virtual environment. It processes text, images, and data to:
• Answer questions
• Generate content
• Analyze patterns
• Support decision-making

Its rapid rise wasn’t accidental. Digital AI benefited from a massive, ready-made dataset: human language and images. For decades, we’ve been writing, storing, and digitizing information—emails, documents, books, photos, websites. It’s been trained on the Internet: the largest repository of language and visuals in human history.

Once that data became accessible, AI systems could be trained quickly and at scale.

That’s why digital AI feels like it “appeared overnight.” It was trained “in the cloud” of ever-expanding data centers, allowing for rapid iteration.  

Physical AI:

Intelligence in the Real World

Physical AI takes the same foundational technologies as digital, on-screen AI—machine learning and neural networks—and applies them to real-world interactions.

Instead of predicting the next word, physical AI must decide:
• What object am I seeing?
• How do I move around safely?
• How hard should I grip this item?
• What action should I take next?

This introduces massive complexity. Instead of just structured data, physical AI must work within the real, unstructured environment, around people and things that don’t always follow the rules. The real world isn’t just data—it’s dynamic, unpredictable, and only governed by physics.

Physical AI needs to account for the 3D space of dimensions, with sensors, actuators, and an understanding of interactions and their outcomes.

Why Physical AI Is Slower to Scale (for Now)

When we built digital AI systems, we chose the right dataset by only using some parts of the internet. Chatbots were built using mostly social media data; Coding Agents were built using mostly open source code data.

Physical AI also requires special data for real world use cases. The world is extremely complex, and the sensors that “see” it can also be complex. But, this time, we can’t just look on the Internet to “find” it. The sensors we use, the environments in which robots move, and the special situations we have to prepare for have simply not been recorded.

Unlike digital AI, physical AI lacks a rich historical dataset like the Internet. There’s no ready made data set for how humans move through environments, how objects behave under force, or how tasks are physically completed. All the physical data must be created, not just collected.

The same generative tools that you use in digital AI can be applied within a simulated world, using real-world, grounded physics, and the physical AI hardware (robots and sensors) can be built alongside the AI. We don’t always have to wait for a robot to go out into the world, record the data, and bring it back to us – the robot isn’t ready yet! Companies like NVIDIA, Tesla, and Amazon are accelerating this by combining compute power, simulation, and real-world data collection.

At Torc, our autonomous driving system, TorcDrive, is being trained to work in the real world using both real-world data (recorded camera and lidar images of on-road driving) as well as complex simulated images created from those same on-road recordings, simultaneously.

The Key Insight: Same Brain, Different Body

The most important takeaway is this: digital AI and physical AI are built on the same core technology. Digital AI is proving what’s possible and adaptable by humans, and most importantly, helpful. Physical AI extends that capability into the real world. Everything you’ve seen AI do on a screen—learning, adapting, improving—will eventually happen in the physical world.

What This Means for the Freight Industry

For freight, logistics, and operations, digital AI helps companies and people think better … physical AI can help you perform better.

At Torc, physical AI is manifested in our autonomous driving software, TorcDrive, and powered by AV 3.0, on our trucks today, after being trained by millions of hours of real world and simulated scenarios. It’s the realization of the promises of hundreds of years of technology and human invention. We are still in early days of building physical AI but the trajectory is clear. Digital AI and physical AI aren’t separate revolutions. They are one and the same.

Meet Your First Physical AI

A physical AI machine you might be familiar with is the in-house robot vacuum. The simplest vacuum has the most basic sensors to register the world around it. If it bumps into something, the computer registers the bump against the moveable panel and turns the wheels to rotate itself in a different direction. Other more expensive models can use sensors to determine floor material, and then adjust how they clean accordingly.

More Going On Under the Hood

There are robot vacuum models with self-emptying functions, pet sensors, and even self-cleaning controls. One of the newest models introduced at CES 2025 even has a robotic arm to pick up socks. As we transition to a more physical AI world, how physical AI “understands” and interacts with its surroundings is very different “under the hood” (or dust bin, in this analogy). It’s becoming more complex, and smarter, and importantly, more applicable and helpful.

Not All Physical AI Thinks the Same

How different physical AI instances and machines “think” and how they must act on their sensors vary widely. It is critical to keep in mind that systems are running ever-increasing AI models, trained on real world and simulation data, designed to interact with the physical world in more capable ways, far exceeding the scalability (and capability) of the first physical AI technologies.

Freight Industry Physical AI Key Applications and Workflows
  • Autonomous Warehouse Operations
  • Intelligent Fleet Management & Safety
  • Dynamic Load Optimization
  • Automated Material Handling
  • And of course … Autonomous Vehicles
AV3.O
AV 3.0: Torc’s AI Blueprint

AV 3.0: Torc’s AI Blueprint

The autonomous ready Freightliner Cascadia, with Torc virtual driver software embedded within the chassis.
Torc has set our sights on one goal: to create a scalable product capable of delivering the immense value of autonomy to our freight partners. The system, hardware, and software must all be built for safety, adaptability, and cost-efficiency; and work seamlessly on Daimler Truck’s Freightliner Cascadia.

And Torc has cracked the code: we’ve designed an unparalleled system that unlocks safe and reliable autonomous driving for long-haul trucking, which can be quickly scaled to meet the needs of our fleet customers. We call it AV 3.0.

AV 3.0

To hit the high goals we set, we recognized that today’s most advanced AI approaches being used to develop autonomy today would not meet the level of capability, performance, and most importantly, safety that the trucking industry requires. We knew we needed to achieve several firsts for autonomous vehicles in parallel: a new autonomous driving architecture as well as a new data and development infrastructure.

Torc tapped our world-class AI talent and our long history in robotics and self-driving vehicles to create AV 3.0: our virtual driver software, the advanced data loop, and generative AI simulation infrastructure to train and test it, setting ourselves apart from others in the industry.

Let’s break down the parts and explain the advanced components of each.

A graphic describing the three parts of Torc's AV 3.0

The Software Product: Virtual Driver

Virtual driver, our autonomous software product driving the truck, is comprised of three main functional modules: perception, prediction, and planning. It is an end-to-end reinforcement-learned (RL) modular software stack with redundant rule-based (heuristic) guardrails. This allows us to uniquely deliver the optimal mix of autonomous driving performance, system reliability, and driving safety. While the machine learning modules in the stack provide the highest driving performance output, Torc layers in rule-based models and arbitration as redundant guardrails, ensuring the ML model doesn’t violate the basic rules of driving.

The addition of the heuristic guardrails is one of the benefits of Torc’s 20-year heritage in developing autonomous vehicle software products. Building rule-based models is an intensive, manual, and time-consuming process, and Torc has been working with heuristic rules as part of our code since the beginning. Also, the addition of rule-based models is inherently verifiable and interpretable since the rules are hand-coded – another layer of verifiability to support a strong safety case.

The modular architecture of the stack provides fine-grained introspection: the ability to see and validate with transparency and explainability if all the learned and heuristic modules are reacting properly to the input. In comparison, an AV 2.0 end-to-end system is a “black box” with just sensor data in and trajectory out. You can’t understand how the stack is reasoning, only that it is reasoning. There’s no way to check on the intermediary results to check if the module is behaving properly and therefore, no way to effectively debug issues. Every time an issue is found, an AV 2.0 end-to-end system must be retrained as a whole with new data specific to that issue to achieve a correct output, but there is no way of knowing if it truly fixed the issue. This “whack-a-mole” approach adds significant time and uncertainty to the software creation and safety validation process.

With our AV 3.0 stack, we can understand how the system is reasoning within each module, in perception, prediction and planning, and where the problems are, retrain the stack with the right set of generated data to specifically target the issue, and supervise the module-level output to validate the fix.

Perceived object bounding boxes and lane centers from the perception module.

The Simulation Environment: Learning to Create the World

Supporting the training of our virtual driver is our world generation and data-driven simulation environment, comprised of several important and complex pieces.

It Always Starts with the Data. We capture real-world data with the actual production-intent sensor suites on our trucks and have collected a breadth of highway and surface street data across many regions and driving conditions.

In fact, Torc has by far the largest set of real-world driving data in autonomous trucking, spanning many diverse scenarios and corner cases.

We then recreate that real-world data within our data-driven simulation environment, giving us the ability to replay those scenes ad infinitum to test the virtual driver. But that real-world data, used repeatedly on replay, is also the starting point for the generative AI environment we’ve developed, to create infinite sequences of challenging driving scenes and scenarios necessary to train and test the virtual driver to meet the needs of our ODD and safety goals.

As no such capability to generate the realistic data needed was available in the market, the Torc AI team leveraged years of research and development to deliver these capabilities, providing us with a unique time, cost, and data fidelity advantage.

In fact, Torc has by far the largest set of real-world driving data in autonomous trucking, spanning many diverse scenarios and corner cases.

These can be summarized as the following three capabilities: 

Neural Rendering

A generative AI approach for realistic scene creation. Based on real world scenes, we can recreate freight-specific, customer-desired sections of road with various “actors” — cars, trucks, animals, pedestrians —  and then generate unique additions and/or changes to the scene, like a car braking hard in front, a wrong way driver, a light snow shower that becomes a blizzard, in a photo-and-lidar-realistic output that can be injected into our perception stack.


World Simulation

This approach generates the other reactive objects that react to our truck (the ego vehicle) and then manages the behaviors however we want or need. We can make reactions more or less aggressive on all of the actors, creating infinite scenes and behaviors. For example, one car captured behaving normally on one section of road can then be made to behave aggressively by degrees. It can go from benign to aggressively merging into the truck’s lane in various places by millimeters and timings by milliseconds.

Importantly, all learned behaviors are grounded in real-world physics-based models, so while we could test with Hollywood-style simulations of flying cars or people, we stay grounded in actualities. We instead simulate vehicles skidding into our lane where in the real-world data, they had been driving carefully in their own lanes.

scenario generation

Scenario generation takes world simulation to the next level, generating never-before-seen road geometries, creating all road conditions, all edge cases, and repeating the simulations through millions of miles, allowing for an even more diverse set of road scenarios. This allows us to quickly adapt the virtual driver software to any new route with minimal additional data collection and time, dramatically accelerating our ability to scale our software to drive new highways, new autonomous hub layouts, in different states, and so on.

Neural Rendering cropping

Real world footage

“For fully data driven simulation, you need to be able to simulate the behaviors and do so very realistically. You also need to be able to control the reactions, in a data-driven way,” says Felix Heide, Head of AI at Torc, and one of the architects of Scenario Dreamer™, a recent diffusion method for scenario generation. “This combination of world simulation systems accomplishes what is necessary.”

The Proof: Training and Testing

Using these layers of world simulation, neural scene rendering together with generated sequences with fully reactive agents, we repeatedly fine-tune and deeply test the virtual driver, as mentioned previously, an instructor teaching a “behind-the-wheel” student, by using reinforcement learning, to explore decision making and provide feedback at the same time.

Virtual driver is taught not only by providing the ideal road trajectory, but also by providing additional scene information so that the system learns to explicitly predict and, on top of that, to explicitly use the information for its final trajectory decision. This, in return, allows a more accurate training process, which, as a byproduct, helps us understand in more detail how the entire system behaves. That detail can then be fed back into the system.

We apply all these techniques to create the data needed to deeply test the virtual driver behavior for the most unusual or unlikely corner cases, to give us high confidence of safe behavior on the road, i.e., that the training of our AI system and the virtual driver has been successful. After that confidence threshold is reached, we move the updated model out of the simulated environment and onto the trucks, validating on both closed course and public roads for every software release.

It’s this high-velocity AV 3.0 framework of data –> training –-> testing –> release that sets an industry benchmark in software development and deployment.

The End Result: Safe and Scalable

“End-to-end systems are critical for scalability. It allows us to be much more adaptable to new needs or to fix issues quickly, and because we have a modular transparent stack, we can see the issues independently,” says C.J. King, Torc Chief Technology Officer. “We can use our generative AI stack to generate the data to train the outcomes rather than train a camera-based object and distance detector, or lidar and radar object detection separately from the prediction and planning. It’s another layer of getting the technology ready for the road.”

This high velocity is critical not only to keep to our release schedule, but to ensure we can quickly enable our customers to scale to new routes and hubs. We can identify, triage, and deploy issues to engineering before we ever encounter them on the road. Additionally, issue resolution and fixes are done within days, not weeks. This turnaround means there can be multiple fixes and releases daily.

Why We Call It AV 3.0

Why do we call it AV 3.0? Torc’s innovation is the next step beyond the technology in AV 1.0 and AV 2.0, as we knew those approaches alone weren’t enough to succeed in creating and deploying autonomous trucks in a timely manner. Torc’s AV 3.0 drives the state of the art in the evolution of scalable, practical, and applied autonomous vehicle software.

Until we reach our product launch in 2027, we will continue to hone this technology, gather more real-world data (something we will always need), develop commercialization plans and hub designs, close our robust safety case, and solve a multitude of other necessary autonomous trucking puzzles. But AV 3.0 provides a clear path to how it can be done. 

So, what’s next?

We’ve defined AV 3.0, the groundbreaking technology used to create, train, and test the virtual driver. What our virtual driver runs on, and how, is another industry-defining element setting Torc apart from the competition. We’re deploying this technology right now, not on prototypes or demonstration trucks, but on the trucks we will go to market with… on production-intent embedded hardware.

Transparency

AV 3.0 understands the state of the entire model and why it acted the way it did, both within individual modules and how it affected the entire end-to-end system. There’s visibility and understanding of what’s always going on inside the model at all times.

Explainability

AV 3.0 permits traceability and verifiability, providing us with the ability to see why and where our virtual driver did something. We can understand both what is detected and what reasoning the system made to determine the object and its meaning. This is crucial for the explainability of our end-to-end system and for our safety case.

Improved Accuracy

Introspection means the AI model is aware of its internal state, how it makes decisions, and its behaviors. Models can understand why they are doing something and can therefore be more accurate.

Let’s explain EXPLAINABILITY and IMPROVED ACCURACY together: AV 3.0 provides object detection outputs and information on the 3D world view our vehicle is in – Is that a car? At what velocity are other highway users travelling at? Is that an emergency vehicle? Where is the lane center? A traffic light? This level of detail allows us to understand what the virtual driver thinks in a certain situation, and we also know how it acts with that information.

Improved Safety

With full transparency of the entire model and individual modules, it is easier to monitor model behavior and verify the software from the inside and explain perception and decision making in full.

Torc’s First Responder Program Recent Highlights

Torc’s First Responder Program Recent Highlights

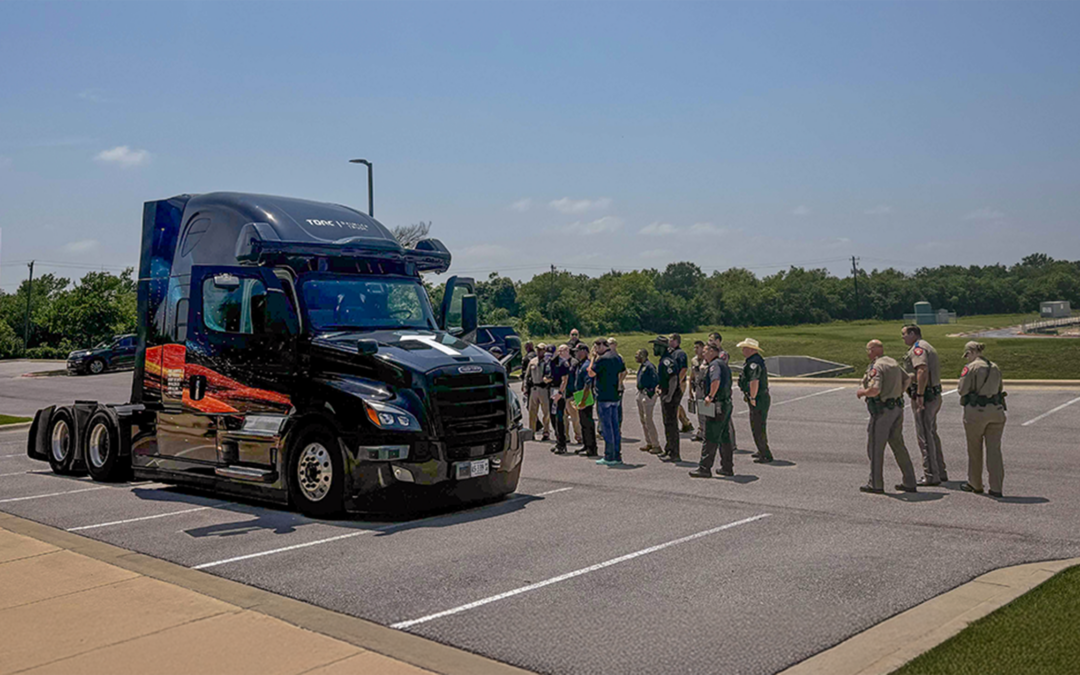
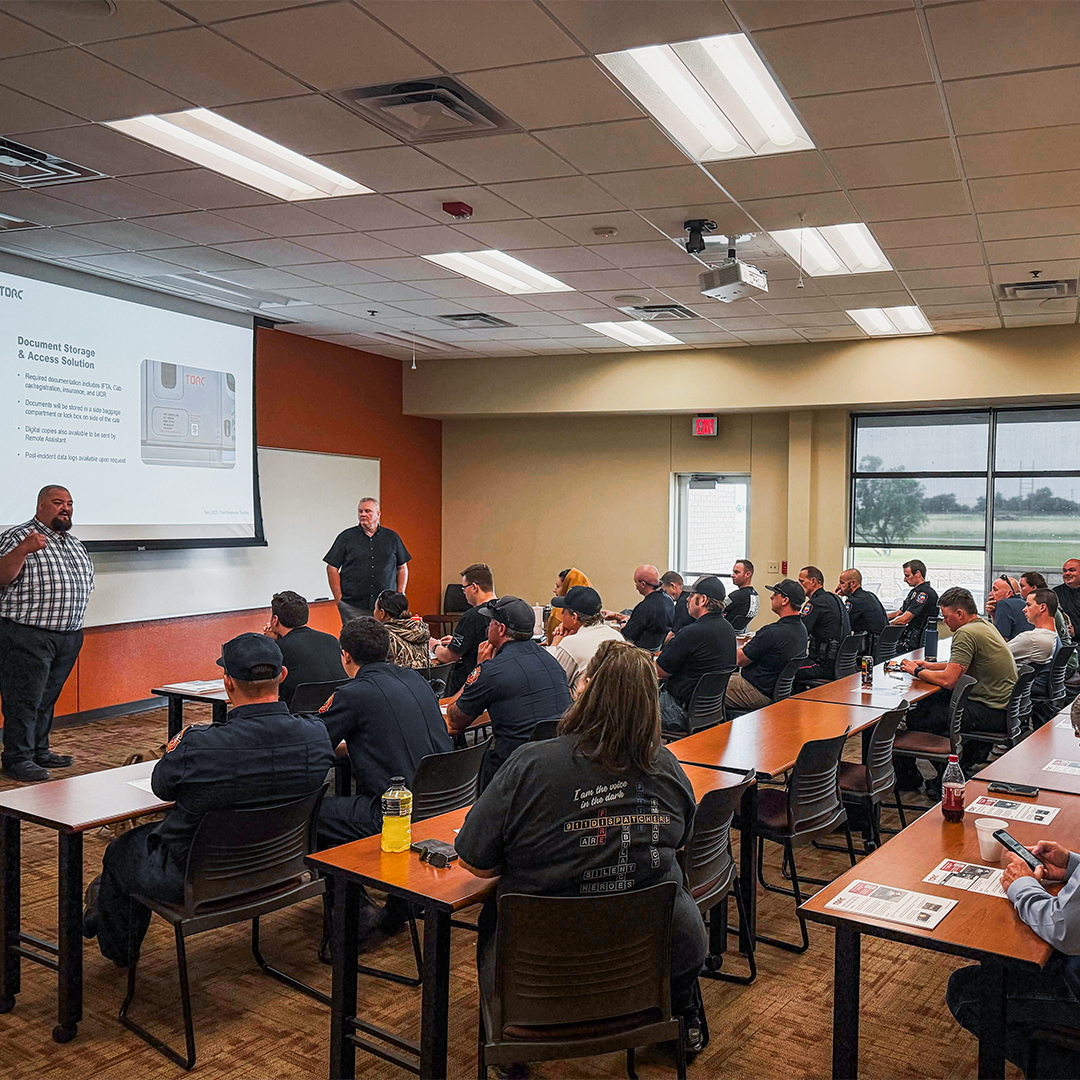
Torc’s First Responder Team recently conducted comprehensive training sessions for more than 150 first responders representing 33 distinct agencies along the Texas I-35 corridor. This initiative is a critical part of Torc’s commitment to preparing the first responder community for interacting with Torc’s self-driving trucks on public roads.

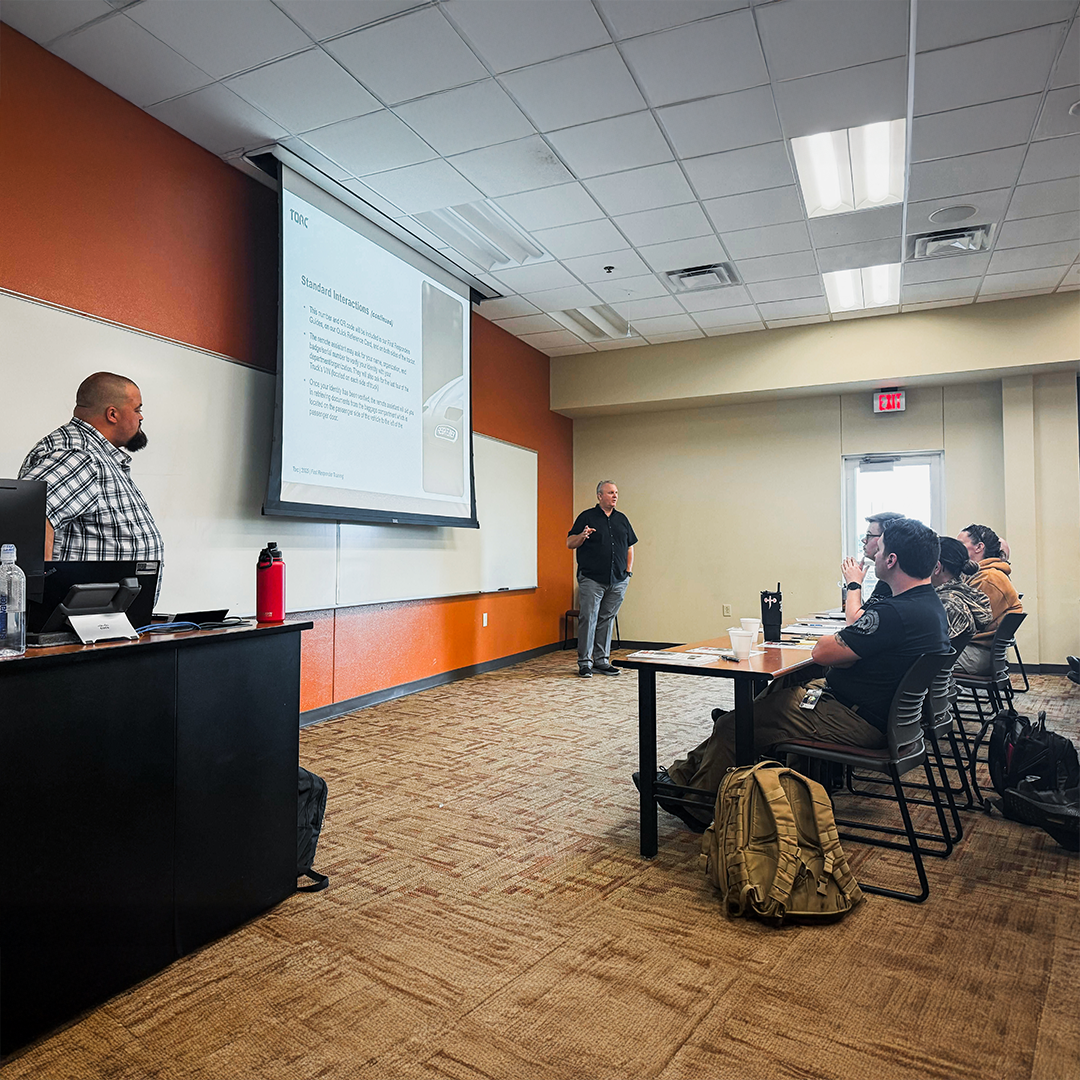
Richard Russell, Senior Manager of First Responder Policy, and Foster Murphy, Fleet Compliance Specialist — with a combined 40+ years of law enforcement experience across city, county, and state levels – delivered training on Torc’s trucks to first responders from various Texas agencies, including Fort Worth PD, Waco PD, Williamson County Sheriff’s Office, and Johnson County Sheriff’s Office.

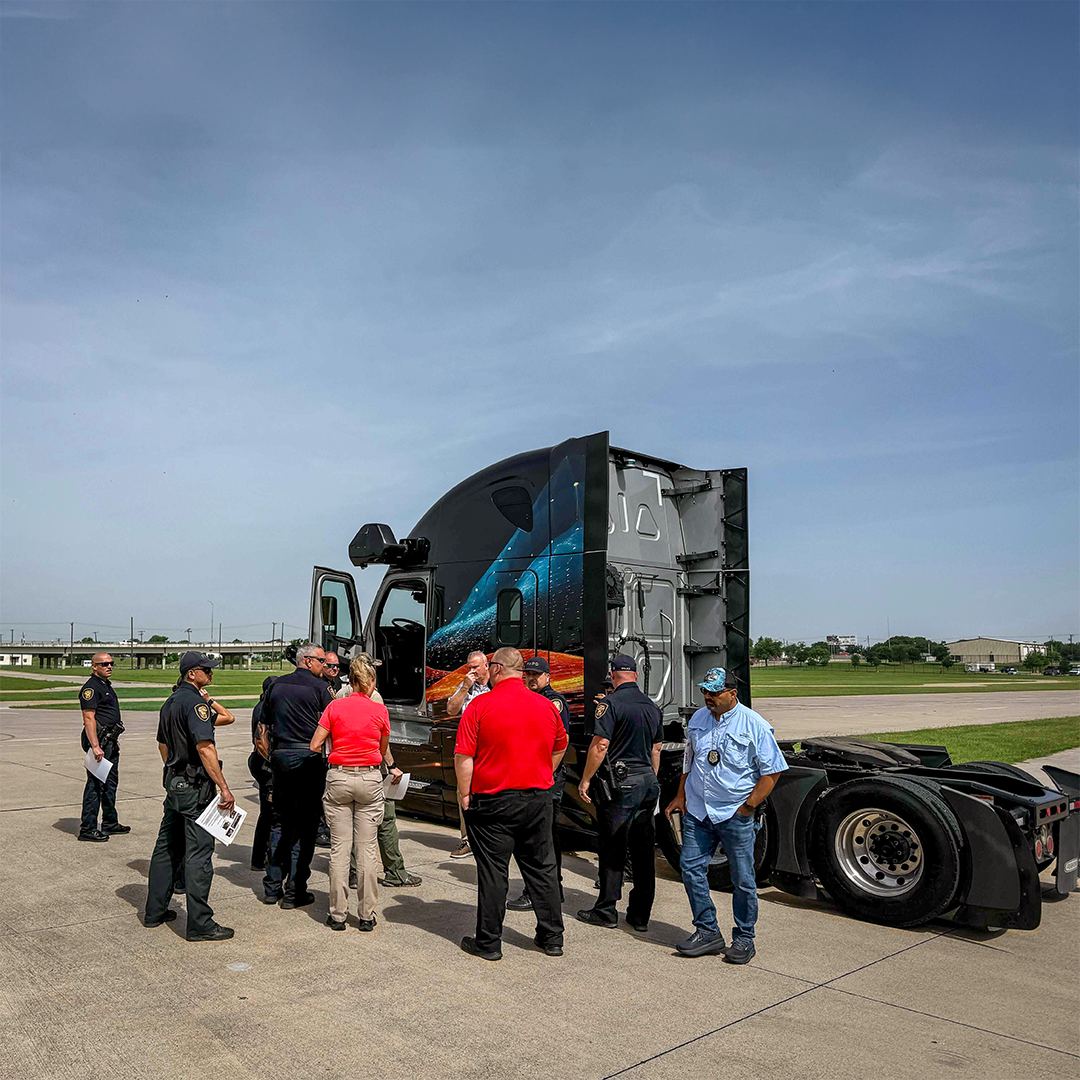
The sessions provided a deep dive into the essentials of autonomy and offered a hands-on experience with the Torc autonomous truck. Over two hours, Richard and Foster guided first responders through the operational mechanics of autonomous commercial motor vehicles, emergency response protocols, and safety procedures to ensure first responders are well-equipped to handle various scenarios involving Torc trucks. 

Looking Ahead

Torc plans to expand its First Responder Training to additional agencies, focusing on where Torc trucks will be operating along I-35 in Texas. Torc is dedicated to fostering trust and collaboration with first responders, recognizing their critical role in ensuring public safety as autonomous technology becomes more prevalent. By continuing to partner with state and local agencies, Torc is committed to advancing the safe adoption of self-driving commercial vehicles, paving the way for a future where innovative technology and public safety go hand in hand.

Check out our First Responder page for more information.