Building the Torc Driverless Safety Case

Building the Torc Driverless Safety Case

A man looking underneath a truck, completing a safety inspection.

As autonomous systems become more complex and physical AI more commonplace, the question for engineering teams is no longer just “Can we build it?”  It’s “Can we prove it’s safe?”

That’s where the safety case comes in.

A safety case is not just documentation. It’s a structured, evidence-based argument to demonstrate that a system is safe for its intended use and operating environment. At Torc, it serves as both a technical framework and an execution tool, linking what we build, how we build it, and how we prove safe deployment.

Why Safety Can’t Be Added Later

One engineering pitfall to avoid is trying to add safety in at the end of the development cycle. In practice, that approach almost always leads to rework, delays, and difficult trade-offs.

A safety case forces a different mindset. It requires that safety be embedded into the development process from the beginning, shaping architecture decisions, tooling, testing strategies, and operational assumptions.

When safety is integrated early, engineering teams gain clarity. They know what evidence will be required, what standards they are working toward, and what being “done” means.

Structuring the Case: Torc’s Three Pillars

At Torc, we’ve structured our safety case on three foundational pillars: Engineer It to Be Safe, Operate It to Be Safe, and the Safety Culture of the Organization.

Engineer It to Be Safe is where most technical effort is concentrated, including designing systems that can handle faults and failures, ensuring safe behavior under normal operating conditions, and building in cybersecurity protections. It involves rigorous hazard analysis, robust system architecture, and comprehensive verification and validation. For engineers, this is where safety requirements translate into design decisions, code, and test coverage.

Operate It to Be Safe ensures that the system is deployed safely in the real world, including monitoring and maintenance processes, and incident response planning and drills. Engineering must account for these realities during development, because operational constraints often feed directly back into system design.

Safety of the Organization reflects the safety culture of the company. Although it is less technical, it directly affects engineering outcomes. It determines whether teams have clear processes, whether issues are surfaced early, and whether safety concerns are addressed systematically. This pillar is the foundation for the integrity of the other pillars.

Different leaders champion these areas; engineers and operations interact with all three, and our Chief Safety Officer is accountable for the whole. Our safety case only works when these domains are aligned.

“If generating safety evidence feels like extra work or is on the critical path, your development process needs to be improved.”

Steve Kenner

Chief Safety Officer

From Claims to Engineering Work

At its core, a safety case is a structured argument. It starts with high-level claims about system safety and breaks them down into smaller, testable assertions. Each of these assertions must be supported by evidence.

For engineering teams, this structure provides a clear way to translate abstract safety goals into concrete work. Instead of asking “Is the system safe?”, the question becomes “What evidence do we need to demonstrate that this specific function, component, or behavior is safe?”

This shift is powerful. It allows teams to define requirements more precisely, assign ownership for specific claims, and track progress in a way that is directly tied to safety outcomes. In practice, this often leads to better alignment between engineering, safety, and program management. It also reduces ambiguity, which is a common source of delays in complex systems development.

A man looking underneath a truck, completing a safety inspection.

Integrating Safety into the Development Process

The Torc safety culture means we integrate safety into the standard development workflow.

Ideally, the same activities that produce the software – design, implementation, and testing – should also produce the artifacts required for the safety case. This includes test results, verification data, process documentation, and traceability between requirements and implementation. Automated continuous integration pipelines, simulation frameworks, and data collection systems all play a role in ensuring that evidence is generated consistently and at scale. This approach removes the need for separate “safety phases” and reduces the risk of last-minute surprises.

Ensuring Completion

The driverless safety case integrates safety throughout the development and verification/validation process to ensure that all safety case claims are comprehensively satisfied. To provide independent assurance of completeness and rigor, Torc engages a third-party to assess the safety case by evaluating the safety case framework, sufficiency of the supporting argumentation, and review the quality and adequacy of the evidence presented for each claim in the safety case. Feedback is given along the way to help ensure the safety case is satisfactory. Third party endorsement of the safety case is one of the gating criteria for driverless deployment.

Designing for Change

Autonomous systems are not static. Software updates, new features, and expanded Operational Design Domains (ODDs) are inevitable. From an engineering perspective, this changeability means the safety case must be treated as a living system. Any change to the system has the potential to impact safety. Engineers need to understand which parts of the safety case are affected, what evidence needs to be updated, and whether existing assumptions still hold.

This is similar to change management in other areas of engineering, but with a stronger emphasis on traceability and impact analysis. Without this discipline, it becomes difficult to maintain confidence in an evolving system or to scale.

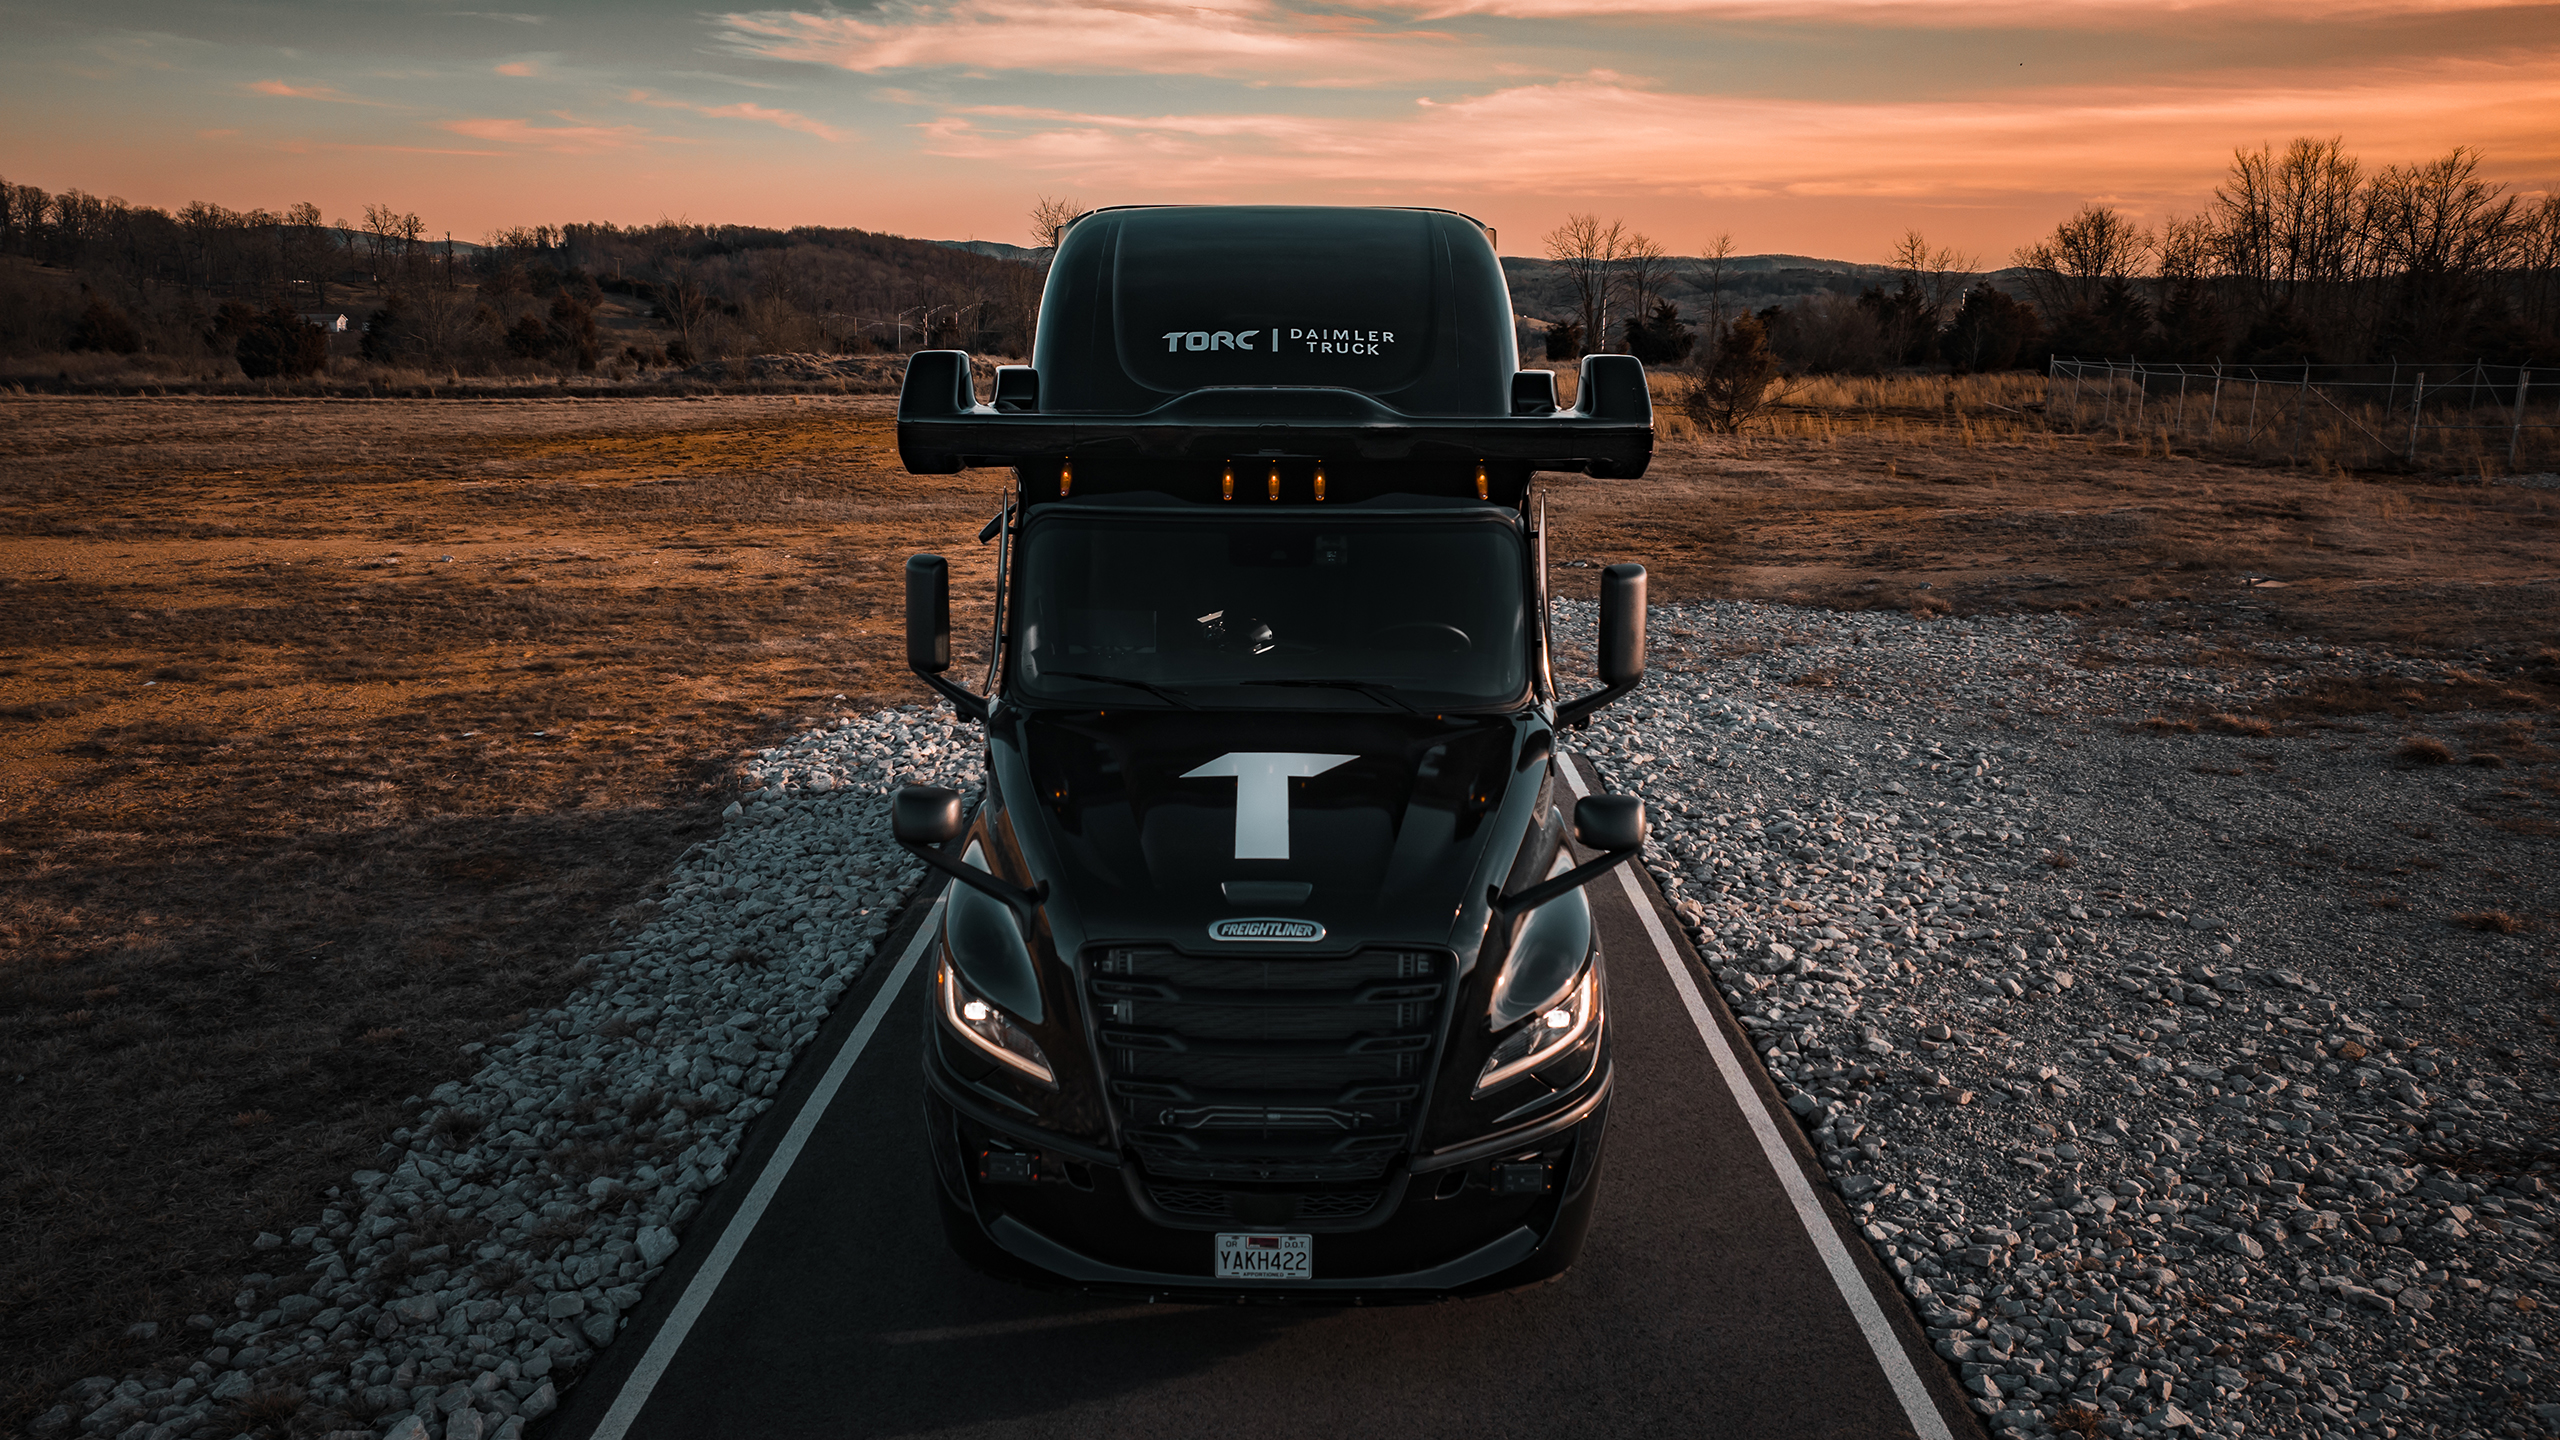
Hoods of Torc modified Freightliner Cascadias

Building Systems That Are Provably Safe

By forcing clarity around claims, evidence, and responsibilities, a safety case provides a structured way to manage complexity. It aligns design, development, and validation activities around a common goal: Demonstrating that the system is safe.

At Torc, safety isn’t a separate concern or a final check. It is an integral part of how our products are being designed, built, and operated. It is the process we use to ensure we honor our obligation to make roadways safer.

Torc Robotics Named First Commercial Partner for Edge Case’s Guardian

Torc Robotics Named First Commercial Partner for Edge Case’s Guardian

Torc truck on highway

Edge Case has launched Guardian, an AI-powered safety intelligence platform designed to give organizations a continuous, system-level understanding of risk across autonomous and complex systems.

Torc Robotics is the first publicly announced commercial partner for Guardian, Edge Case’s AI-powered safety intelligence platform. As Torc advances the commercialization of autonomous trucking for long-haul freight, Guardian helps provide continuous visibility into the safety profile of its self-driving system throughout development. By connecting safety analyses, engineering data, and design decisions, the platform enables teams to identify hazards earlier and address risk before it becomes more costly to resolve. The collaboration demonstrates how integrating safety intelligence from the earliest stages of development can support safer, more scalable autonomous operations and accelerate the path to commercial deployment.

Strengthening Autonomous Truck Safety Through First Responder Collaboration

Strengthening Autonomous Truck Safety Through First Responder Collaboration

Torc truck reflection in side mirror

Bringing Real-World Expertise to Autonomous Vehicle Development

On July 16, 2026, law enforcement officers, firefighters, and EMS personnel from agencies across the southwest Virginia region joined Torc engineers and safety experts for a series of targeted testing exercises at the Virginia Tech Transportation Institute (VTTI) Smart Road closed-course test track to further evaluate how our self-driving truck detects, interprets, and responds to emergency vehicles and personnel in real-world scenarios.

The goal was simple but critical: to better understand how autonomous vehicles can safely and effectively interact with emergency responders in dynamic traffic situations as well as roadside environments.

Using our most recent generation of Torc self-driving trucks (SDTs) on the VTTI Smart Road, the team conducted emergency vehicle (EMV) data collection across a variety of realistic scenarios. These exercises allowed Torc to expand its training dataset, gather valuable operational insights, and further improve the system’s ability to recognize and respond appropriately to emergency situations.

For autonomous vehicles operating on public roads, emergency interactions represent some of the most complex and unpredictable conditions they may encounter. Ensuring that self-driving trucks can accurately detect emergency vehicles, interpret responder actions, and make safe driving decisions is an essential part of building a dependable autonomous system.

Learning From Those Who Know the Road Best

First responders bring a unique perspective that informs Torc engineers as they build our technology. Throughout the testing exercises, participating officers, firefighters, and EMS personnel shared insights based on years of frontline experience. From traffic stops and roadside incidents to emergency response situations, these professionals understand how complex these situations can become. Their feedback helps Torc refine how Torc’s autonomous truck perceives and reacts to these complex scenes, improving the predictability of the autonomous truck, and ultimately increasing the safety for responders, other motorists, and the communities where autonomous vehicles will operate. “First responders need clear answers in emergency situations: Will the autonomous vehicle stay put or move? Can they safely work around it? Is anyone inside? Our First Responder Interaction Plan was designed to address those critical questions, “says Richard Russell, Senior Program Manager, First Responder Policy.

Expanding Data, Improving Performance

The event also delivered significant technical value.

High-quality emergency vehicle and responder interaction data is critical for improving perception systems. Every scenario performed at the test track contributes to a broader and more diverse dataset that can be used to enhance the truck’s ability to recognize emergency vehicles under varying conditions and respond appropriately.

“Collaboration with first responders is essential to developing safe, reliable autonomous vehicle technology,” says Erik Kinservik, Director of Engineering. “Working directly with law enforcement, fire, and EMS helps us understand real-world operational needs and ensures our vehicles respond appropriately in emergency situations, improving safety, supporting effective emergency response, and building public trust.”

“Using our latest generation vehicle, we expanded our high-quality data set, covering a wide breadth of scenarios across the multiple onsite police, fire, and rescue vehicles,” says Zach Joswick, Senior Software Engineer. “By capturing this widely varied data in both static and dynamic situations, our AV 3.0 software can learn the diverse range of shapes and sizes of EMVs and respond accordingly. Our simulation environment can take the captured data, and generate thousands of permutations to even further enhance the AV 3.0 model’s capability to respond to complex emergency situations.”

By expanding this data foundation, Torc continues to strengthen the reliability and robustness of its autonomous driving system, ensuring it is prepared to operate safely across a wide range of real-world situations.

Three Torc trucks, taken from above by drone
Photo of an autonomous truck visualization on screen

Building Partnerships That Matter

Beyond the technical outcomes, collaborations like this reinforce the importance of strong relationships between autonomous vehicle developers and the public safety community.

Developing autonomous technology is not something that happens in isolation. It requires ongoing collaboration with the people who will interact directly with these systems on the road. By working side by side with first responders, Torc receives valuable operational insight from industry experts while providing transparency into how autonomous vehicles are being developed and tested.

“Building autonomous technology isn’t just about advancing the vehicle. It’s about building strong partnerships with the people who will interact with it every day,” says Russell. “Working alongside first responders helps us create safer systems while fostering the trust that’s essential for successful deployment.”

These partnerships help ensure that safety remains at the center of innovation while also building trust among stakeholders and the broader public.

A Shared Commitment to Safer Roads

The success of Torc’s alliance with First Responders highlights what can be accomplished when diverse groups come together around a common mission. Engineers, operators, law enforcement officers, firefighters, and EMS personnel regularly collaborate to advance a shared goal: creating safer roadways through thoughtful innovation and rigorous testing.

“Ongoing engagement is essential because we know we won’t anticipate every question. That’s why maintaining an open dialogue with first responders is such an important part of what we do,” says Russell.

As Torc continues to develop autonomous trucking technology, ongoing collaboration with first responders will remain a critical part of the journey. Their expertise, partnership, and dedication help us build systems that are not only technologically advanced, but also safe, practical, and responsive to the realities of the road.

At Torc, safety is the foundation of everything we do. Building a safe and reliable autonomous trucking solution requires more than advanced technology. It requires close collaboration with the people who work every day to keep our roads safe, and together, we are helping shape the future of transportation, one built on safety, operational integrity, and strong collaboration.

Proven, Not Promised: Earning Our Place on the Road

Proven, Not Promised: Earning Our Place on the Road

Torc truck on Texas highway

At Torc, safety isn’t just a priority; it’s the foundation that supports every aspect of how we develop, deploy, and operate our autonomous trucking technology. As we work to transform commercial freight transportation, we’ve built an approach that establishes trust with regulators, our customers, and the public, that Torc’s autonomous solutions are safe to deploy and in the communities we operate in.

Torc’s Chief Safety Officer, Steve Kenner, and his team have developed a safety framework organized around three pillars that guide our safety philosophy. Individually, they keep different parts of our whole team accountable to specific segments, such as the engineering of our trucks, how they’re operated, and how safety is fostered within Torc. Together, they ensure we’re not just building a safe autonomous truck but operating it responsibly.

Build it Safe

The foundation of our safety approach starts with the truck itself. We’ve engineered multiple layers of redundancy into our hardware as well as our autonomous driving systems, embedded on the industry-leading Freightliner Cascadia platform, to ensure safe operation even when individual components fail.

  • Redundancy at Every Level

Our redundancy approach encompasses all critical systems. Our safety philosophy spans all aspects of our technology, from our system architecture to our hardware and software design, allowing us to be resilient to failures. This is accomplished through redundancies in our safety-critical systems, such as braking and steering.

For instance, if an individual sensor fails, we can achieve an MRC (minimal risk condition) by pulling off the road at a safe location. The redundancies we’ve built in allow us to continue operating safely.

  • Intelligent Fault Management

Torc has developed a sophisticated fault-management system that detects faults, including safety-relevant faults, and matches them to appropriate responses. Our priority hierarchy is clear: first and foremost, our trucks must maintain safe operations and refrain from creating a hazard for other road users. If we can’t reach our destination, we focus on degraded operation that gets us to a safe location, rather than just pulling to the roadside. Think truck stop or exit ramp, not highway shoulder. However, in safety-critical situations, our autonomous truck will pull over to the side of the road as soon as it is safe to do so.

  • Addressing Edge Cases

Edge cases (problems or situations that occur at the extreme limits of a system’s operating parameters) are inevitable in the real world. Whether it’s a billboard featuring a giant stop sign that could be misidentified by sensors, or a pickup truck loaded with Christmas trees, our autonomous driving system needs to handle a multitude of scenarios not previously encountered. Torc is tackling this challenge through a collaboration with Stanford University, where we’ve partnered to make the future of freight safer for all. By sharing our data and perception information with our partners, we’re able to compare datasets and identify differences between them. For instance, let’s say our simulation training data includes lots of pickups loaded with wooden planks, but we don’t have any of those same “real world” vehicles in our on-road perception data. These kinds of insights allow us to identify areas where we should develop a more complete perception dataset.

We also leverage publicly available crash databases from the National Highway Traffic Safety Administration and state agencies to analyze crashes on our planned routes (as well as roads outside of our routes) but within our ODD or operational design domain, which the set of specific conditions and locations under which an automated system can/is allowed to operate. This allows us to replay and recreate these scenes during software testing, using AI generated scenarios in our simulation environment. We can test and train the software’s responses to both real-world crashes and even more challenging simulated situations.

    • The Role of Simulation and Testing

    Let’s dive deeper into Torc’s simulation environment and our testing and training. Torc firmly believes that you cannot real-world-road-test our way to safety. Even millions of miles on the road wouldn’t be enough to encounter all potential edge cases. Therefore, we use a balanced combination of (1) real-world data and (2) generated AI simulated scenarios to test our software, and then (3) retraining the system as a whole. We use safety metrics, such as hard breaking, hard swerves, and total time to collision that allow us to measure performance in both environments and establish parity between simulation and on-road results.

    Our comprehensive simulation libraries provide scalable, cost-effective testing capabilities, but we still need sufficient on-road miles to validate our software against real-world performance.

    Operate it Safe

    Technology is only part of the safety equation. With autonomous trucking, Torc is improving how freight operations work and realize efficiencies, prompting new approaches to maintenance, inspection, and human oversight:

    • Evolving Operational Standards. Our autonomous technology requires updated maintenance and inspection protocols compared to traditional trucking operations, such as sensor calibration and increased frequency. We’re developing the training programs and procedures that will equip fleet operators and technicians with the skills they need to work with autonomous vehicles.
    • Human Oversight Philosophy. We’re establishing clear guidelines as to when remote assistance should assist a vehicle when it encounters situations that may require human oversight. This balance ensures that human judgment enhances rather than undermines our autonomous capabilities.
    • Consistent Standards Everywhere. Safety standards must be maintained across different routes, terminals, and regulatory environments. We’re building systems that adapt to varying environments while maintaining our core safety principles.

    Trust It To Be Safe

    We recognize that the biggest challenge we face now isn’t necessarily technical; Torc has already overcome that. It’s earning public trust. We’re committed to establishing and maintaining trust and safety from our drivers, regulators, partners, and our community at large.

    • Transparency and Engagement

    As Torc CSO Steve Kenner puts it, “We’re all in charge of public safety.” We maintain transparency with regulators and elected officials who are responsible for public safety, engaging with stakeholders at city, county, state, and federal levels. We want people to understand what we’re doing, how we’re doing it, and when we’re doing it. This includes comprehensive first responder interaction plans and training programs, ensuring that emergency personnel understand how to interact safely with our vehicles.

    • Independent Validation

    We understand that industry self-assessment isn’t enough. That’s why we’re working with third parties like Stanford’s Center for AI Safety and Edge Case Research; we’re actively seeking out neutral third-party studies and evaluations of our work to ensure that we’ve created a complete picture of our safety case.

    • Industry Collaboration

    Torc believes that rising tides lift all boats, so, while we compete on many aspects of our business, we should always collaborate on safety. We participate in industry consortiums and safety organizations, such as the Automated Vehicle Safety Consortium, sharing knowledge that advances autonomous vehicle safety across the entire sector, while respecting antitrust and intellectual property requirements.

    How It All Comes Together: Governance and Risk Management

    These three pillars of Torc’s safety approach don’t operate in isolation; they’re connected through a comprehensive governance structure centered on risk management. We’ve established a flexible safety governance framework where safety decisions can be promptly reviewed by a cross-functional team of experts. These committees report up to the Torc safety board, which CSO Steve Kenner leads.

    Safety risk management is pervasive throughout our approach. We systematically identify safety hazards and develop mitigation strategies across all our operations, whether we’re selecting hardware, planning operations, or making any other business decisions. Our safety risk management framework provides the structure for how we assess and evaluate these safety risks.

    Earning Our Place on the Road

    As autonomous trucking technology continues to mature and regulatory frameworks evolve, our three-pillar safety philosophy provides a comprehensive approach to the complex challenges of deploying self-driving vehicles at scale. We’re not just working to put autonomous trucks on the highway – we’re working to earn their place there through demonstrated safety, reliability, and responsible operation.

    The transformation of commercial transportation will succeed only if we can prove that autonomous vehicles operate safely alongside human drivers while delivering the efficiency and economic benefits they promise. Our systematic approach to safety, governance, and public engagement is designed to make that vision a reality.

    At Torc, safety isn’t just what we do; it’s who we are. Every decision we make, every system we build, and every mile we drive is guided by our commitment to operating safely and earning the trust of everyone who shares the road with us.

    New Phase of Torc–Edge Case Collaboration Targets Production-Ready Safety Case

    New Phase of Torc–Edge Case Collaboration Targets Production-Ready Safety Case

    Sunny drone shot of the Torc Ann Arbor office location

    Independent safety assessments by Edge Case mark a pivotal step in Torc’s journey toward commercializing Level 4 autonomous trucking

    Blacksburg, VA — August 19, 2025 – Torc, a pioneer in commercializing self-driving class 8 trucks, today announced a new strategic collaboration with Edge Case (EC), frontier technologies and safety-critical systems experts. This next phase of collaboration will support Torc’s mission to fully commercialize Level 4 autonomous trucks for long-haul applications in the U.S., ensuring its driverless safety case aligns with the applicable AVSC Best Practices and guidance from the Open Autonomy Safety Case (OASC). This alignment will result in a more streamlined, well-structured, safety case that improves clarity, accelerates development, and enhances cross-functional review.

    This initiative will focus on a series of independent assessments of Torc’s Driverless Safety Case Framework and Evidence Sufficiency Criteria, reinforcing Torc’s commitment to safety and independent validation in preparation for production and commercialization. Looking ahead, Edge Case will conduct an assessment of completed safety case evidence. These assessments will be conducted independently by Edge Case and will include detailed reports and collaborative review sessions with Torc’s safety, engineering and operations teams.

    “Edge Case brings world-class expertise in building rigorous and comprehensive safety programs,” said Jerry Lopez, Senior Director of Safety Assurance at Torc. “Their leadership and experience across multiple autonomy segments make them an ideal partner as we move toward production readiness.”

    This announcement comes on the heels of Torc’s recent appointment of Steve Kenner as Chief Safety Officer and the company’s ongoing prioritization of safety through integrated, cross-functional collaboration.

    “This partnership with Torc represents a pivotal step forward in advancing autonomous trucking safety,” said Nathan Parker, Chief Executive Officer of Edge Case. “By leveraging our deep experience across autonomy domains, we’re helping ensure that Torc’s safety case is not only rigorous and transparent, but also production-ready for real-world deployment.”

    With this collaboration, Torc is advancing toward its goal of launching fully driverless, commercial autonomous trucks for long-haul applications in the U.S. by 2027.

    About Torc

    Torc, headquartered in Blacksburg, Virginia, is a global leader and pioneer in trucking. Founded in 2005 at the birth of the self-driving technology, Torc has 20 years of experience in pioneering safety-critical, self-driving applications. Torc is working toward a complete self-driving vehicle software and integration solution and is currently focusing on commercializing autonomous trucks for long-haul applications in the U.S. In addition to its Blacksburg headquarters and engineering offices in Austin, Texas, and Montreal, Canada, Torc has a fleet operations facility in the Dallas-Fort Worth area in Texas, to support the company’s productization and commercialization efforts, as well as a presence in Ann Arbor, MI, to leverage the autonomous and automotive talent base in that region. Torc’s purpose is driving the future of freight with autonomous technology. As the world’s leading autonomous trucking solution, we empower exceptional employees, deliver a focused, hub-to-hub autonomous truck product, and provide our customers with the safest, most reliable, and cost-efficient solution to the market.

    About Edge Case

    Edge Case is the trusted technical partner for companies working with frontier technologies and sophisticated systems. Headquartered in Pittsburgh, Pennsylvania, Edge Case supports industry leaders across automotive, aerospace, defense, energy, and AI as they design, build, and deploy complex, critical systems. With deep expertise in autonomy, functional safety, and systems engineering, Edge Case helps teams navigate evolving regulatory landscapes and operational risk. Utilizing DevSafeOps, Edge Case enables organizations to digitize safety workflows, generate defensible safety cases, and accelerate readiness for launch. Whether supporting autonomous vehicles, robotic systems, or next-generation AI applications, Edge Case is on a mission to ensure a safer tomorrow.


    Contacts

    Laura Lawton, 408-505-5820
    press@torc.ai