Building the Torc Driverless Safety Case

Building the Torc Driverless Safety Case

A man looking underneath a truck, completing a safety inspection.

As autonomous systems become more complex and physical AI more commonplace, the question for engineering teams is no longer just “Can we build it?”  It’s “Can we prove it’s safe?”

That’s where the safety case comes in.

A safety case is not just documentation. It’s a structured, evidence-based argument to demonstrate that a system is safe for its intended use and operating environment. At Torc, it serves as both a technical framework and an execution tool, linking what we build, how we build it, and how we prove safe deployment.

Why Safety Can’t Be Added Later

One engineering pitfall to avoid is trying to add safety in at the end of the development cycle. In practice, that approach almost always leads to rework, delays, and difficult trade-offs.

A safety case forces a different mindset. It requires that safety be embedded into the development process from the beginning, shaping architecture decisions, tooling, testing strategies, and operational assumptions.

When safety is integrated early, engineering teams gain clarity. They know what evidence will be required, what standards they are working toward, and what being “done” means.

Structuring the Case: Torc’s Three Pillars

At Torc, we’ve structured our safety case on three foundational pillars: Engineer It to Be Safe, Operate It to Be Safe, and the Safety Culture of the Organization.

Engineer It to Be Safe is where most technical effort is concentrated, including designing systems that can handle faults and failures, ensuring safe behavior under normal operating conditions, and building in cybersecurity protections. It involves rigorous hazard analysis, robust system architecture, and comprehensive verification and validation. For engineers, this is where safety requirements translate into design decisions, code, and test coverage.

Operate It to Be Safe ensures that the system is deployed safely in the real world, including monitoring and maintenance processes, and incident response planning and drills. Engineering must account for these realities during development, because operational constraints often feed directly back into system design.

Safety of the Organization reflects the safety culture of the company. Although it is less technical, it directly affects engineering outcomes. It determines whether teams have clear processes, whether issues are surfaced early, and whether safety concerns are addressed systematically. This pillar is the foundation for the integrity of the other pillars.

Different leaders champion these areas; engineers and operations interact with all three, and our Chief Safety Officer is accountable for the whole. Our safety case only works when these domains are aligned.

“If generating safety evidence feels like extra work or is on the critical path, your development process needs to be improved.”

Steve Kenner

Chief Safety Officer

From Claims to Engineering Work

At its core, a safety case is a structured argument. It starts with high-level claims about system safety and breaks them down into smaller, testable assertions. Each of these assertions must be supported by evidence.

For engineering teams, this structure provides a clear way to translate abstract safety goals into concrete work. Instead of asking “Is the system safe?”, the question becomes “What evidence do we need to demonstrate that this specific function, component, or behavior is safe?”

This shift is powerful. It allows teams to define requirements more precisely, assign ownership for specific claims, and track progress in a way that is directly tied to safety outcomes. In practice, this often leads to better alignment between engineering, safety, and program management. It also reduces ambiguity, which is a common source of delays in complex systems development.

A man looking underneath a truck, completing a safety inspection.

Integrating Safety into the Development Process

The Torc safety culture means we integrate safety into the standard development workflow.

Ideally, the same activities that produce the software – design, implementation, and testing – should also produce the artifacts required for the safety case. This includes test results, verification data, process documentation, and traceability between requirements and implementation. Automated continuous integration pipelines, simulation frameworks, and data collection systems all play a role in ensuring that evidence is generated consistently and at scale. This approach removes the need for separate “safety phases” and reduces the risk of last-minute surprises.

Ensuring Completion

The driverless safety case integrates safety throughout the development and verification/validation process to ensure that all safety case claims are comprehensively satisfied. To provide independent assurance of completeness and rigor, Torc engages a third-party to assess the safety case by evaluating the safety case framework, sufficiency of the supporting argumentation, and review the quality and adequacy of the evidence presented for each claim in the safety case. Feedback is given along the way to help ensure the safety case is satisfactory. Third party endorsement of the safety case is one of the gating criteria for driverless deployment.

Designing for Change

Autonomous systems are not static. Software updates, new features, and expanded Operational Design Domains (ODDs) are inevitable. From an engineering perspective, this changeability means the safety case must be treated as a living system. Any change to the system has the potential to impact safety. Engineers need to understand which parts of the safety case are affected, what evidence needs to be updated, and whether existing assumptions still hold.

This is similar to change management in other areas of engineering, but with a stronger emphasis on traceability and impact analysis. Without this discipline, it becomes difficult to maintain confidence in an evolving system or to scale.

Hoods of Torc modified Freightliner Cascadias

Building Systems That Are Provably Safe

By forcing clarity around claims, evidence, and responsibilities, a safety case provides a structured way to manage complexity. It aligns design, development, and validation activities around a common goal: Demonstrating that the system is safe.

At Torc, safety isn’t a separate concern or a final check. It is an integral part of how our products are being designed, built, and operated. It is the process we use to ensure we honor our obligation to make roadways safer.

Torc Robotics Named First Commercial Partner for Edge Case’s Guardian

Torc Robotics Named First Commercial Partner for Edge Case’s Guardian

Torc truck on highway

Edge Case has launched Guardian, an AI-powered safety intelligence platform designed to give organizations a continuous, system-level understanding of risk across autonomous and complex systems.

Torc Robotics is the first publicly announced commercial partner for Guardian, Edge Case’s AI-powered safety intelligence platform. As Torc advances the commercialization of autonomous trucking for long-haul freight, Guardian helps provide continuous visibility into the safety profile of its self-driving system throughout development. By connecting safety analyses, engineering data, and design decisions, the platform enables teams to identify hazards earlier and address risk before it becomes more costly to resolve. The collaboration demonstrates how integrating safety intelligence from the earliest stages of development can support safer, more scalable autonomous operations and accelerate the path to commercial deployment.

Torc Robotics Joins Auto-ISAC to Strengthen Cybersecurity Collaboration Across Connected Commercial Vehicles 

Torc Robotics Joins Auto-ISAC to Strengthen Cybersecurity Collaboration Across Connected Commercial Vehicles 

Torc truck on highway

Membership supports Torc’s continued focus on secure, resilient autonomous trucking systems as the company advances toward commercialization 

BLACKSBURG, Va – August 3, 2026 – Torc Robotics, a pioneer in self-driving vehicle technology, today announced it has joined the Automotive Information Sharing and Analysis Center (Auto-ISAC), a global member-driven organization dedicated to advancing cybersecurity collaboration across the automotive industry.

As autonomous trucks become more connected and integrated into the freight ecosystem, cybersecurity is an essential part of building systems that are safe, reliable and ready for commercial deployment. Through Auto-ISAC, Torc will collaborate with automakers, suppliers and commercial vehicle organizations to share cyber threat intelligence, contribute to emerging best practices and help strengthen the resilience of connected vehicle technologies.

“Cybersecurity isn’t added at the end of development; it’s built into the product from the design stage,” said Mike Westra, Senior Director of Product Cybersecurity at Torc. “As we prepare to commercialize and scale autonomous trucking, participating in Auto-ISAC helps us strengthen our approach in collaboration with the broader autonomous industry, ensuring our product is designed to address evolving cyber threats throughout its lifecycle.”

Auto-ISAC provides a trusted forum for members to share timely cyber threat intelligence, develop cybersecurity best practices and coordinate responses to emerging threats across the automotive sector. Torc’s participation reflects its broader commitment to industry collaboration as the company continues developing autonomous trucks for long-haul freight operations in the U.S.

“Delivering autonomous trucks at commercial scale requires disciplined engineering across safety, security, reliability and operations,” said Mike Avitabile, Chief Engineering Officer at Torc. “Our participation in Auto-ISAC strengthens that work by helping ensure cybersecurity advances alongside the broader technology and industry ecosystem.”

Through its membership, Torc will participate in Auto-ISAC working groups and collaborate with industry peers on cybersecurity guidance, information sharing and best practices for connected and autonomous vehicle systems.

“The cyber threat landscape is constantly evolving, and no organization can stay ahead of it alone,” said Faye Francy, executive director, Auto-ISAC. “By joining Auto-ISAC, Torc is strengthening an industry-wide community dedicated to sharing cyber threat intelligence, advancing best practices and supporting the secure deployment of autonomous commercial vehicles.”

About Torc

Torc is driving the future of freight with autonomous technology. With more than 20 years of experience in pioneering safety-critical, self-driving applications, Torc offers an AI-forward, self-driving vehicle software and integration solution and is currently focusing on commercializing autonomous trucks for long-haul applications in the U.S. In addition to its Blacksburg headquarters and engineering offices in Ann Arbor, MI, and Montreal, Torc has a fleet operations facility in Dallas-Fort Worth, to support the company’s productization and commercialization efforts for our customers. As an independent subsidiary of Daimler Truck AG, a global leader and pioneer in trucking, Torc is empowering exceptional employees, delivering a customer-focused autonomous truck product, and providing the safest, most reliable, and cost-efficient solution to the market. For more information, please visit torc.ai.

About Auto-ISAC

The Auto-ISAC was formed by automakers in 2015 to establish a global information-sharing community to address vehicle cybersecurity and operate as a central hub for sharing, tracking, and analyzing intelligence about emerging cybersecurity risks. Auto-ISAC members represent more than 99 percent of light-duty vehicles on the road in North America. Members also include heavy-duty vehicles, commercial fleets, carriers, and suppliers. For more information, please visit www.automotiveisac.com.
From Black Box to Glass Box: AV 3.0, Physical AI, and the Future of Long-Haul Trucking 

From Black Box to Glass Box: AV 3.0, Physical AI, and the Future of Long-Haul Trucking 

In 2025, Torc introduced AV 3.0, our framework for building autonomous software that is safe, scalable, and designed specifically for long-haul trucking autonomy. It powers TorcDrive, the physical Al virtual driver software that perceives, reasons, and navigates the real world in real-time.

We’ve had a lot of questions about our AV 3.0, evolution and how it differs from, and surpasses, the autonomous software industry as a whole. Here’s a breakdown of all the predecessors to our AV 3.0, what makes TorcDrive different and distinctive, and why we believe it sets the benchmark for state-of-the-art ADS systems.

Rules-Based Approaches and AV 1.0: Open Books and the First Learned Models

It all began with rules-based, open book software. In 2007, the Torc team VictorTango drove Odin, a 2005 Ford Escape hybrid designed to navigate complex urban environments without human intervention. The system successfully drove through roundabouts, intersections, and cross-traffic using a rule-based architecture, where the vehicle behavior was governed by pre-programmed, deterministic logic (if-then statements). Such early systems were highly interpretable and traceable. Each decision could be linked back to a specific rule, sensor input, or subsystem. This made it possible to diagnose failures with precision. In the mid-2010s, the emergence of deep learning enabled the initial move to AI with a massive improvement in perception performance, allowing vehicles to better detect objects, understand lane structure, and interpret complex scenes. This is what we refer to as AV 1.0, a hybrid approach combining learned perception models with rule-based prediction and planning. These architectures operated on inputs from cameras, lidar, radar, high-definition maps, and hand-coded rules of the road. However, these systems were inherently brittle, since downstream behavior prediction and planning components remained largely hand-engineered. It’s nearly impossible to imagine every scenario in advance and code appropriate rules to handle it. As a result, this architecture, combining first-generation learned perception models with rules-based prediction and planning, were not capable enough for the complexity of fully autonomous driving. Operating with distinct rules in silos, AV 1.0 vehicles were often stymied by simple situations that a human would negotiate without a second thought, like a misplaced construction cone or worn-away lane markings. AV 1.0 was far from being a scalable commercial product that could replace drivers.
Fear of a Machine You've Never Met

Most Americans are anxious about how quickly AI is advancing. That anxiety is especially pronounced with physical AI—machines that use sensors to perceive, reason, and move around in the real world in real time—like TorcDrive. But few Americans have directly interacted with any Physical AI systems.

According to polling, 87% of Americans have never ridden in an autonomous vehicle, or even know someone who has.

Not All Autonomy Is the Same

Much of society is limited to forming opinions based heavily on eye-catching headlines hyped by algorithms eager for clicks and eyeballs. All of us benefit from learning about the fundamental differences between the powerful physical AI quietly driving autonomous freight trucks and the AV systems in private vehicles and robotaxis making the evening news.

AV 2.0: A Magic Black Box

In the last five years, we’ve seen a massive leap in vehicle capabilities with AV 2.0 end-to-end learned platforms. This is one of the leading directions in AV research, moving beyond heavily rule-based planning and map-dependent architectures toward unified learned systems. Instead of relying on hand-designed rules for each part of the driving stack, AV 2.0 driving solutions leverage advances in deep learning, generative modeling, and large-scale data to train models that can run in-vehicle and connect perception, prediction, planning, and control within a single learned framework. Like the large language models we increasingly use every day, these systems are capable of impressive results. But that capability comes with a major tradeoff: opacity. In a highly integrated end-to-end model, it can be difficult to determine why the vehicle behaved a certain way, where an error originated, or how to make a targeted correction without affecting other parts of the system. A change intended to improve behavior in one scenario can introduce regressions elsewhere, requiring large-scale retraining, validation, and testing. This makes development more expensive, slows iteration, and creates uncertainty around how behavior may shift from one model update to the next. For long-haul trucking, the challenge is even greater. Safe physical AI for heavy trucks requires more than what is sufficient for robotaxis or passenger vehicles. Trucks operate with longer stopping distances, reduced maneuverability, different visibility constraints, and a need for long-range perception, prediction, and planning. The next generation of autonomous trucking must combine the deterministic confidence and traceability of rule-based autonomy, the modular structure and debuggability of AV 1.0, and the performance gains of the end-to-end approach in AV 2.0.

AV 3.0: The Transparent Glass Box

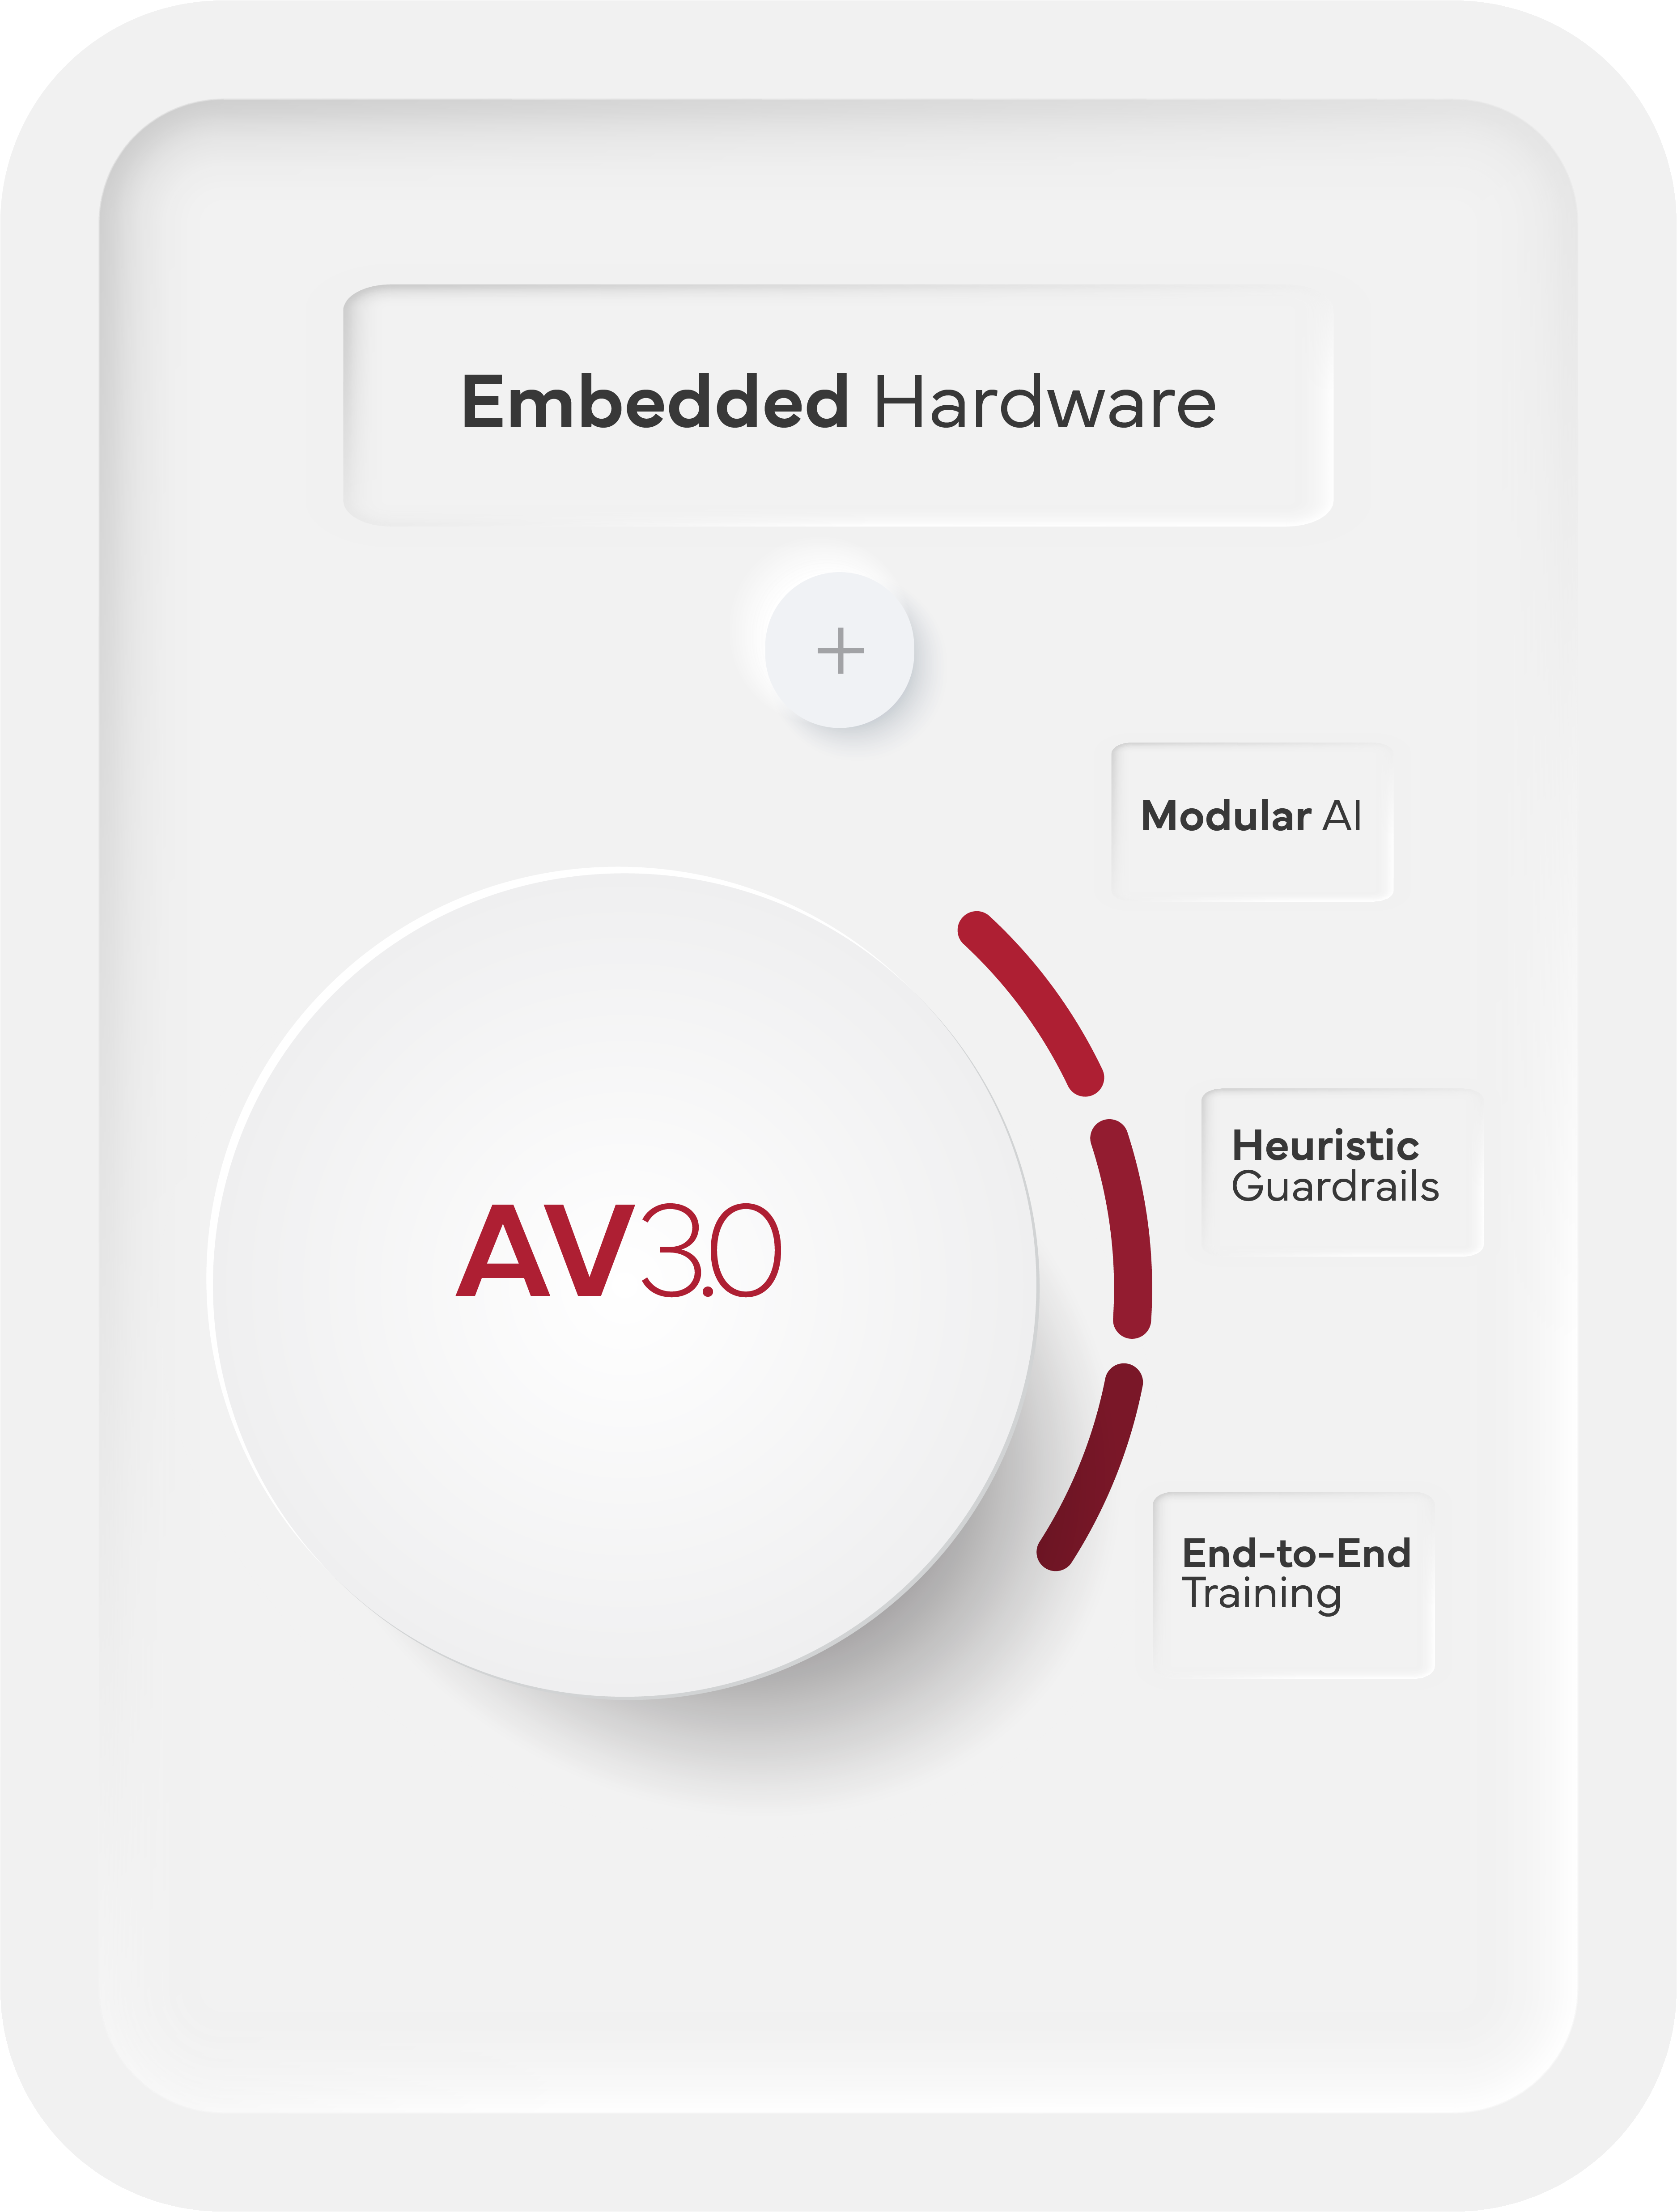
The next generation of autonomy should not force a choice between the traceability of rules-based systems and the performance of modern end-to-end AI. Torc’s approach combines modular approaches, deterministic guardrails, and end-to-end training into what we call AV 3.0: a transparent architecture for autonomous trucking. Rather than a black box approach to autonomy, AV 3.0 is designed as a “glass box”, a system whose major components can be inspected, validated, and improved with precision. This approach is structured to provide visibility into how the truck perceives the world, predicts the behavior of other road users, and selects a safe driving plan. To develop AV 3.0, Torc has the high-powered simulation and data loop needed to train, test, and validate TorcDrive before we deploy it on public roads. The result is a scalable autonomous trucking software product designed for the complexity, safety requirements, and operating realities of long-haul freight.
A graphic describing the three parts of Torc's AV 3.0

1. A Verifiable AI stack

TorcDrive automated driving software is organized around three core functional modules: Perception, Prediction, and Planning. Together, these modules allow the system to understand the driving environment, anticipate how surrounding actors may behave, and generate safe driving plans for the truck. This forms a modular learned software stack that is learned in an end-to-end manner, and is supported by deterministic, rule-based guardrails and clearly defined safety criteria. This modular structure makes the system more inspectable, testable, and verifiable than a single black-box end-to-end model. Engineers can examine intermediate outputs from each stage of the stack and validate whether the different components are responding appropriately to the input. When changes need to be made, Torc can target specific elements of the stack, validate at the module-level output, and then test the full system in closed-loop conditions before deployment. Equally important as the modular structure of the AI stack is how TorcDrive is trained and validated.

2. Immersive AI Training and Validation

Before it reaches the road, TorcDrive is trained and tested through a large-scale data and simulation loop designed to expose the system to the complexity of real-world trucking. This can be seen as the autonomous trucking equivalent of a CDL driver-education program, except the system is specifically tested in rare, complex, and safety-critical scenarios at a scale no human driver could encounter in a lifetime. Torc accomplishes this using our proprietary generative simulator trained on real-world data captured by production-intent sensor suites on over-the-road trucks. Torc’s generative AI and data-loop environment creates a large and continually expanding set of challenging driving scenarios grounded in real-world data and physics-based modeling. These scenes include cars, trucks, pedestrians, animals, varied road geometries, changing conditions, and rare edge cases that are difficult to collect repeatedly through road testing alone. Our immersive training environment accelerates TorcDrive’s ability to learn new routes and autonomous hub layouts, allows it to quickly adapt to regional driving conditions, and prepare for challenging scenarios such as severe weather, unexpected pedestrian encounters, or rare vehicle behaviors. Simulation does not replace real-world validation, but it greatly expands the range of situations TorcDrive can experience before deployment.

3. Seamless Hardware Integration

In 2019 Torc Robotics became an independent subsidiary of Daimler Truck NA, the world’s largest and leading OEM, bringing together extensive experience in freight industry manufacturing and relationships with Torc’s experience in developing autonomous vehicle solutions. This is the first strategic alliance between an autonomous vehicle technology firm and a truck original equipment manufacturer (OEM), gathering all of the essentials needed to create a scalable Class 8 SAE Level 4 truck. Together, Torc and Daimler Truck have developed a truck purpose-built for fully self-driving autonomous operation in long-haul trucking and production at scale. It combines a Verifiable AI stack hosted on a proprietary NVIDIA-powered embedded compute platform provided by Flex, with sensors, other hardware, and Daimler’s autonomous-ready 5.0 Freightliner Cascadia. This chassis is specifically designed for SAE Level 4 autonomous operation, with all the essential compute stack components and sensors installed on the production line. Complete with necessary redundancies for safety-critical components, the vehicle and platform have been proven and validated for highway operations. This is the first autonomous freight vehicle to fully transition to a production-ready, purpose-built platform—the autonomy validated from the wheels up from the beginning, not bolted-on after the fact.

Riding Along as the Future Unfolds

Over the coming weeks, we’ll be sharing more detailed pieces of our product and how it has been developed on the Al-powered technology wave. What’s down the road? Connect with us to see what’s next.

​

Torc Robotics Announces First-Ever Autonomous-Trucking Partnership at Mila to Advance Physical AI

Torc Robotics Announces First-Ever Autonomous-Trucking Partnership at Mila to Advance Physical AI

Hoods of Torc modified Freightliner Cascadias

Montréal, QC and Blacksburg, VA, May 26, 2026 — Torc Robotics, a pioneer in self-driving vehicle technology, today announced a new strategic partnership with Mila – Quebec Artificial Intelligence Institute, one of the world’s leading centers for machine learning research.

Through this collaboration, Torc will establish a presence within Mila’s ecosystem in Montreal, becoming the only autonomous trucking company to join the institute, and gaining access to top-tier academic talent, including students, researchers, and faculty. The partnership also includes dedicated research space on site and is designed to build on Torc’s existing AI and autonomy research to deepen its capabilities in physical AI through direct collaboration with Mila’s faculty and researchers.

Mila is globally recognized for its contributions to machine learning and applied AI research, with a large community of researchers, strong ties to leading universities in Canada, and a reputation as a launchpad for top AI talent, with alumni and affiliates holding leadership roles in well known companies such as OpenAI and Google.  By embedding within Mila’s collaborative environment, Torc will deepen its research capabilities in emerging areas of autonomy, including generative world models, multi-agent behavior modeling, reinforcement learning, and foundation models for physical AI systems.

“Torc is focused on building safe, scalable autonomous trucks, and advancing the next generation of physical AI is central to that mission,” said Felix Heide, Head of Artificial Intelligence at Torc. “As a long-time Mila collaborator, I can definitively say that partnering enables deeper collaboration at the intersection of research and real-world deployment, collaboration that supports continued progress toward commercializing autonomous trucking at scale.”

“We are excited to welcome Torc as an industry partner, as it becomes an even stronger component of Mila’s ecosystem,” said Christopher Pal, Core Academic Member at Mila, Scientific Co-Director of IVADO and Professor at Polytechnique Montréal. “This partnership brings together academic excellence and real-world deployment, creating opportunities for our students and researchers to work on impactful challenges in physical AI while advancing the state of the art in autonomous systems.”

The partnership builds on Torc’s existing presence in Montreal and an affiliation with Mila that dates back to 2020, reinforcing its commitment to investing in global AI talent and research partnerships. Together, Torc and Mila will explore new approaches to physical AI that bridge simulation and real-world performance, helping to unlock safer and more efficient autonomous transportation.

“As autonomous vehicle technology becomes closer to a reality, it is exciting and important to see new collaborations between academic labs and top tier companies that are bringing the technology to market,” said Liam Paull, a Core Academic Member at Mila, a Canada CIFAR AI Chair, and an Associate Professor at Université de Montréal, where he co-leads the Montréal Robotics and Embodied AI Lab (REAL).


About Torc

Torc is driving the future of freight with autonomous technology. Torc has more than 20 years of experience in pioneering safety-critical, self-driving applications. Torc offers an AI-forward, self-driving vehicle software and integration solution and is currently focusing on commercializing autonomous trucks for long-haul applications in the U.S. In addition to its Blacksburg headquarters and engineering offices in Ann Arbor, MI, and Montreal, Torc has a fleet operations facility in Dallas-Fort Worth, to support the company’s productization and commercialization efforts for our customers.  As an independent subsidiary of Daimler Truck AG, a global leader and pioneer in trucking, Torc is empowering exceptional employees, delivering a customer-focused autonomous truck product, and providing the safest, most reliable, and cost-efficient solution to the market.


About Mila – Quebec Artificial Intelligence Institute

Founded by Professor Yoshua Bengio, Mila – Quebec Artificial Intelligence Institute is the world’s largest academic AI research center specialized in deep learning, home to a community over 1500 members strong. Based in Montreal, Mila was created out of a unique partnership between Université de Montréal and McGill University, dedicated to advancing scientific breakthroughs that drive innovation and ensure AI benefits everyone. A non-profit organization, Mila is strongly supported by the Government of Canada through the Pan-Canadian AI Strategy and by the Government of Quebec. Internationally recognized for its influential research, global innovation partnerships, and leadership in multilateral efforts on responsible AI, Mila continues to shape the future of AI worldwide. For more information, visit mila.quebec.


The autonomous ready Freightliner Cascadia, with Torc virtual driver software embedded within the chassis.